プロジェクト
国際学術誌・国際会議で発表した研究のうち、専用ウェブページのあるプロジェクトをご紹介します。
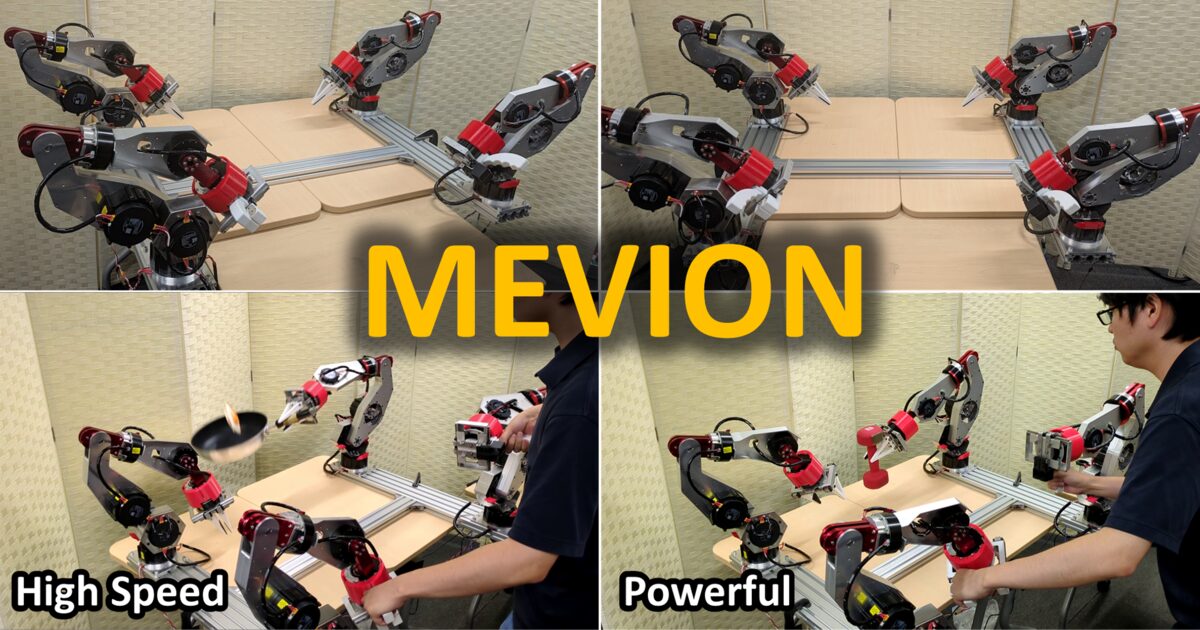
MEVION: Low-Cost Open-Source Data Collection System for Powerful and High-Speed Dual-Arm Manipulation
K. Kawaharazuka, Y. Obinata, H. Ishida, J. Oh, T. Suzuki, S. Inoue, K. Yoneda, A. Iwata, K. Okada
IEEE Robotics and Automation Practice (RAP), 2026
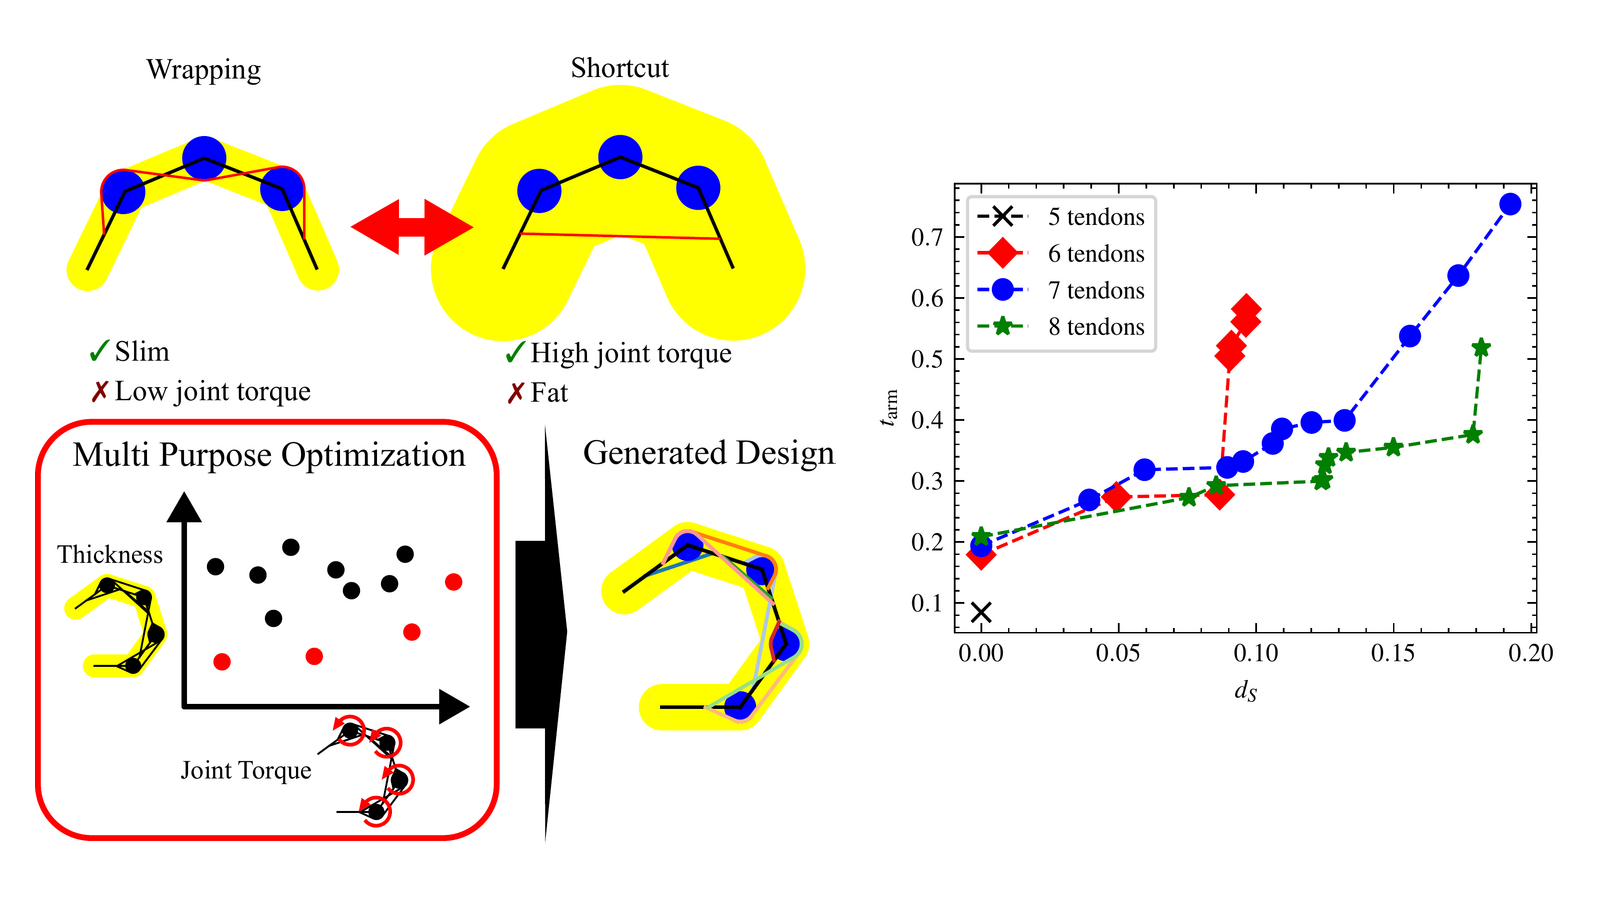
Design optimization of tendon-driven robots considering tendon wrapping and shortcut
Y. Sahara, K. Kawaharazuka, K. Okada
Advanced Robotics (AR), 2026
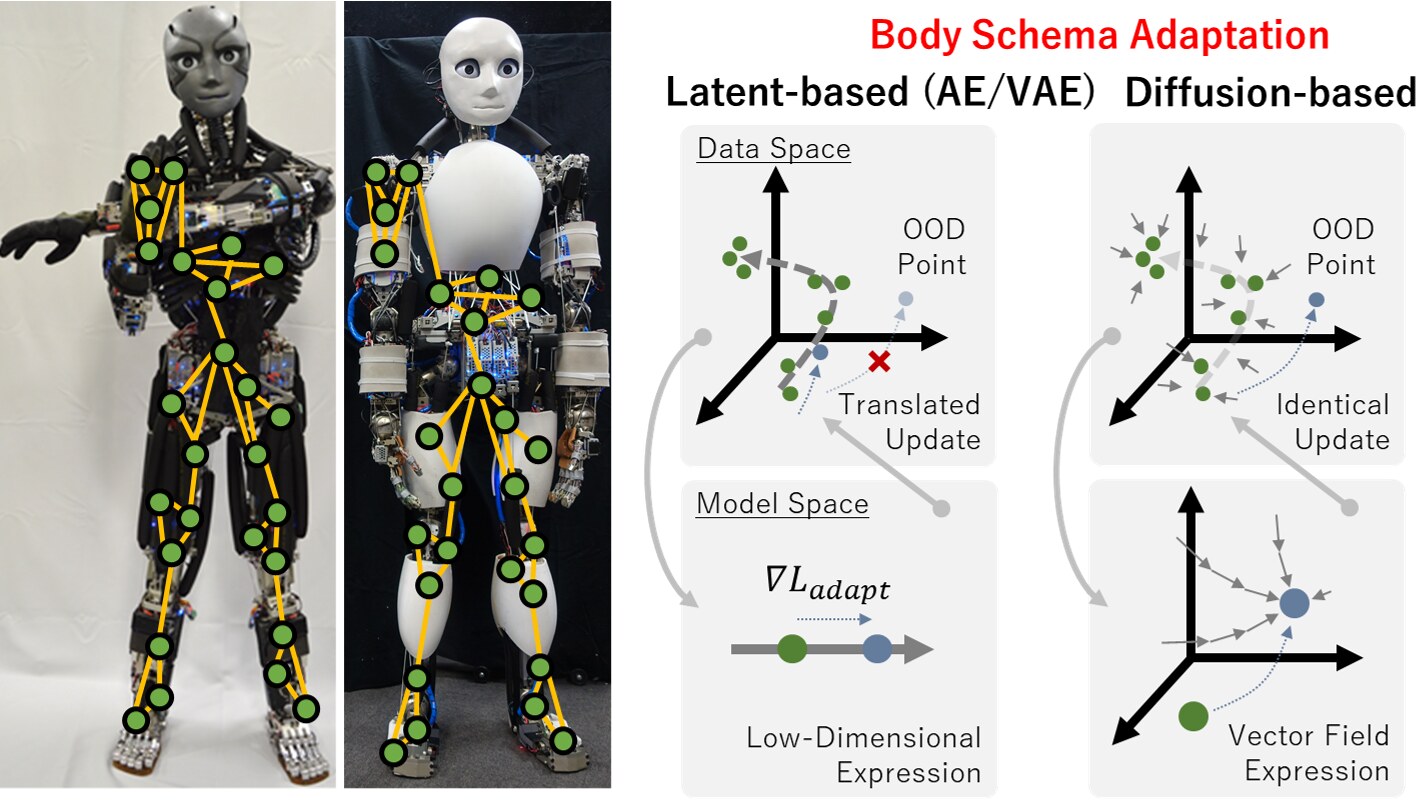
Diffusion-Based Body Schema Learning Enabling Abnormal-State Adaptation in Musculoskeletal Robots
K. Kawaharazuka, S. Ikemoto
IEEE Robotics and Automation Letters (RAL), 2026
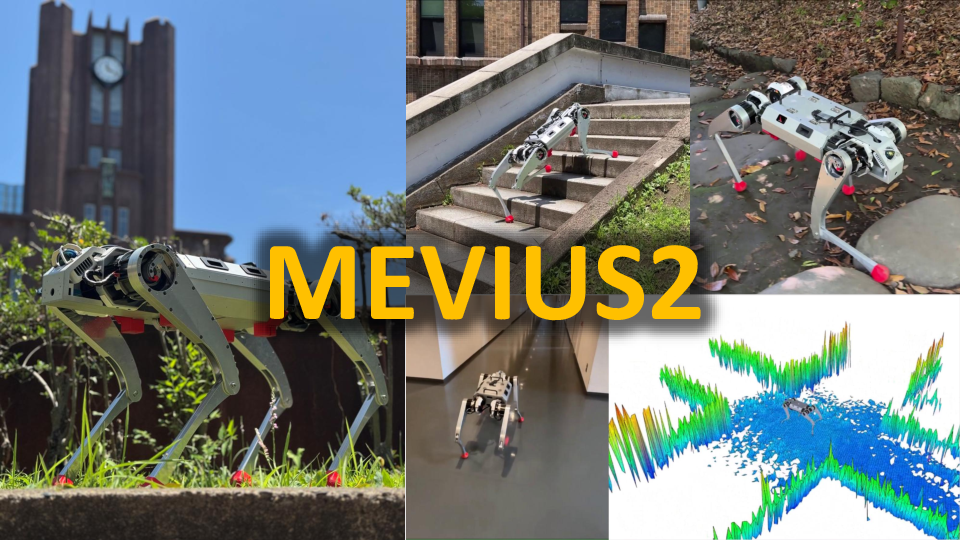
MEVIUS2: Practical Open-Source Quadruped Robot with Sheet Metal Welding and Multimodal Perception
K. Kawaharazuka, K. Yoneda, S. Inoue, T. Suzuki, J. Oda, K. Okada
IEEE Robotics and Automation Practice (RAP), 2026
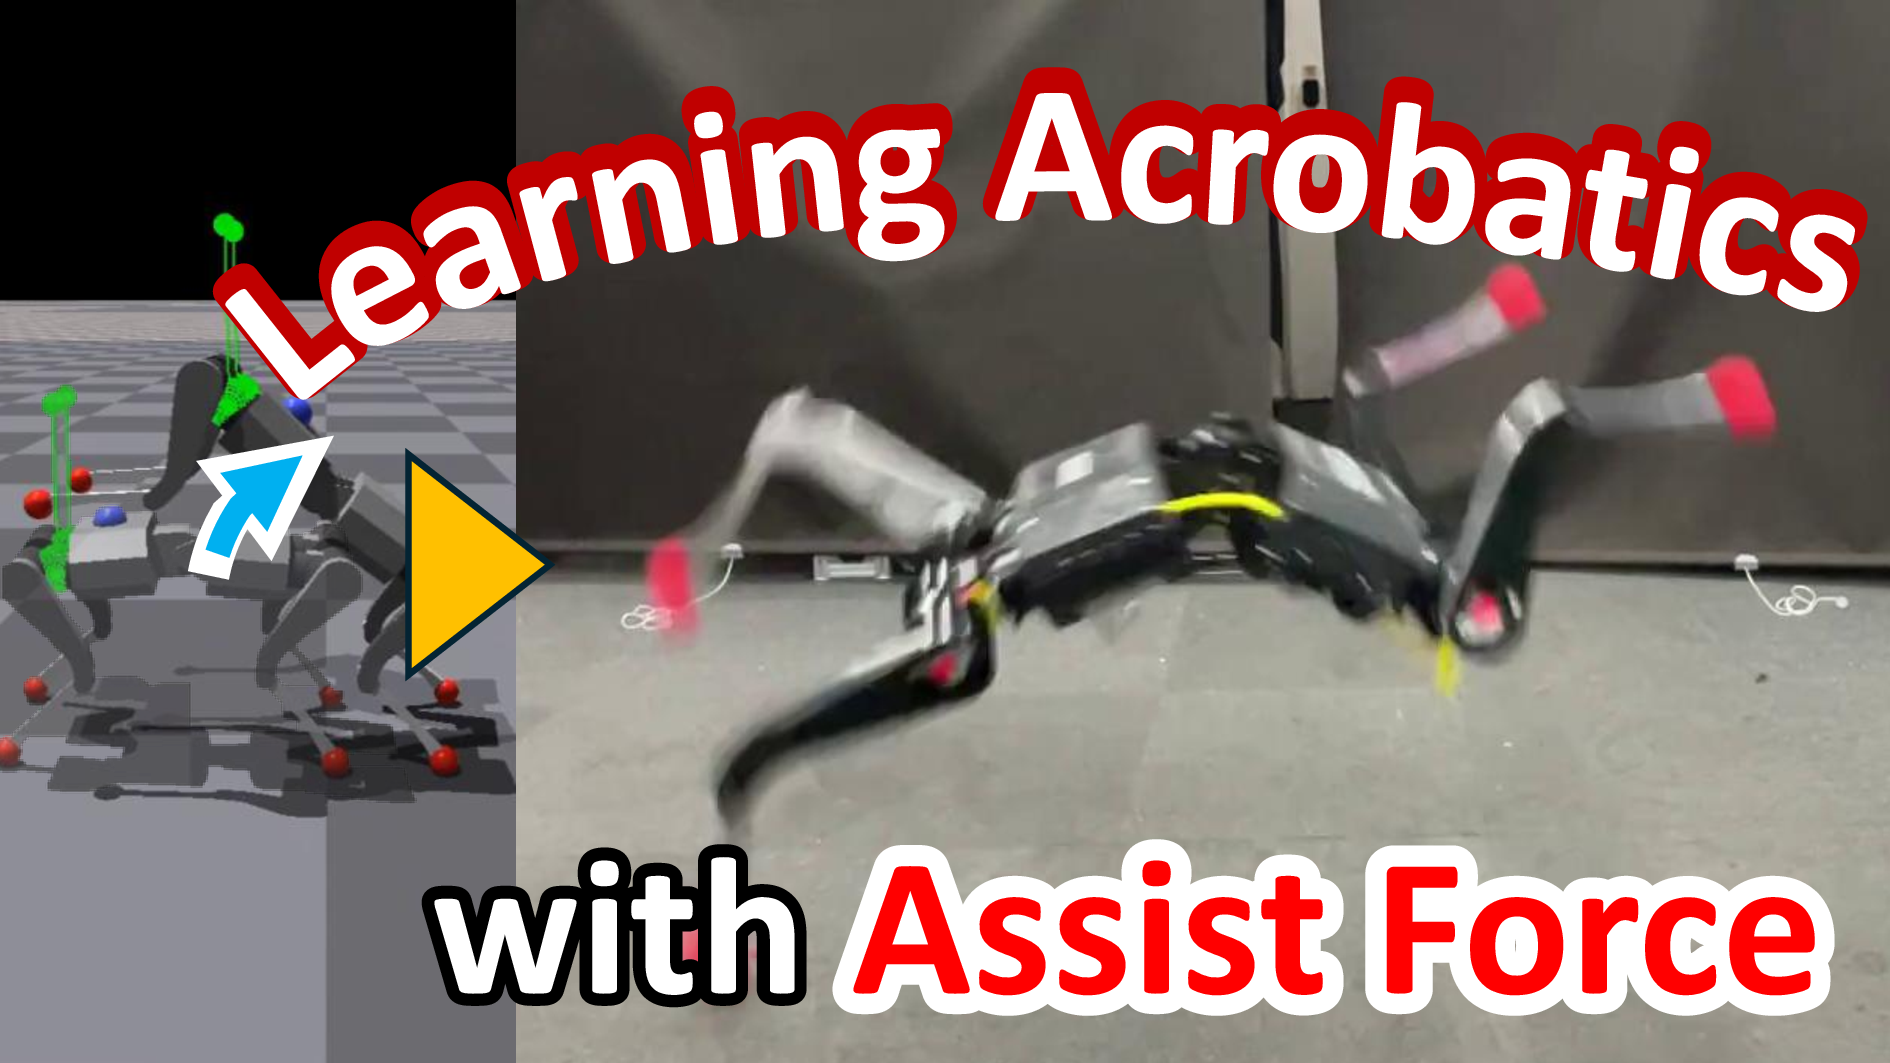
EFGCL: Learning Dynamic Motion through Spotting-Inspired External Force Guided Curriculum Learning
K. Yoneda, K. Kawaharazuka, K. Okada
IEEE Robotics and Automation Letters (RAL), 2026
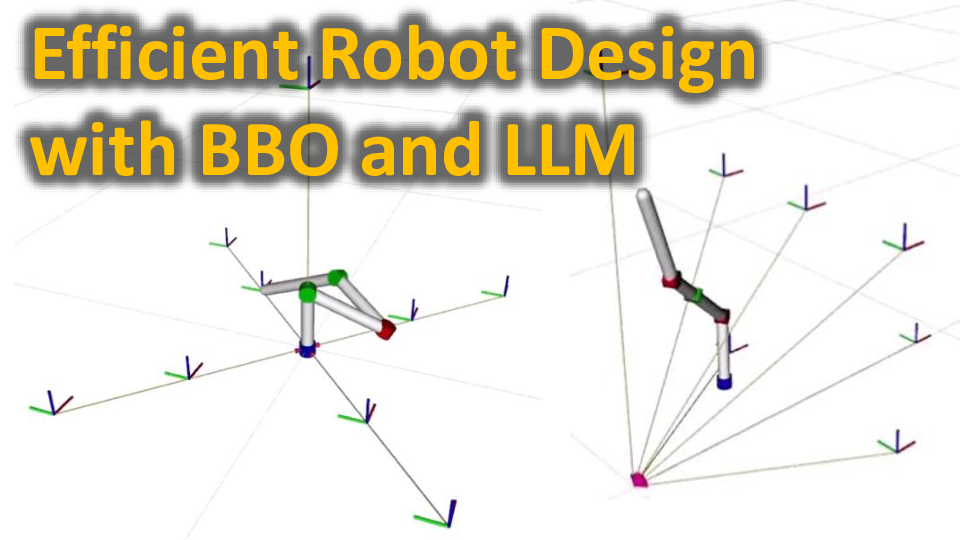
Efficient Robot Design with Multi-Objective Black-Box Optimization and Large Language Models
K. Kawaharazuka, Y. Obinata, N. Kanazawa, H. Jia, K. Okada
IEEE Access, 2026
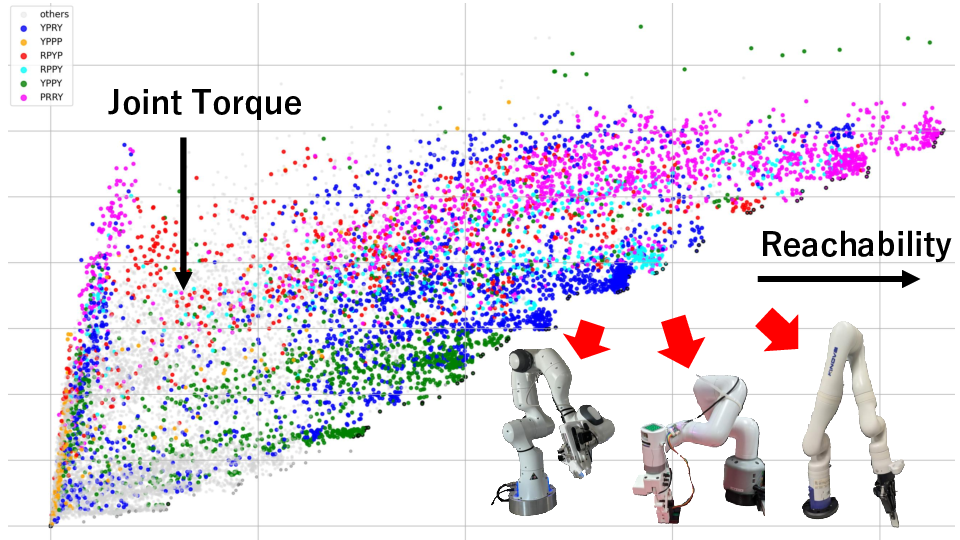
Analysis of Various Manipulator Configurations Based on Multi-Objective Black-Box Optimization
K. Kawaharazuka, K. Yoneda, T. Hattori, S. Inoue, K. Okada
Advanced Robotics (AR), 2026
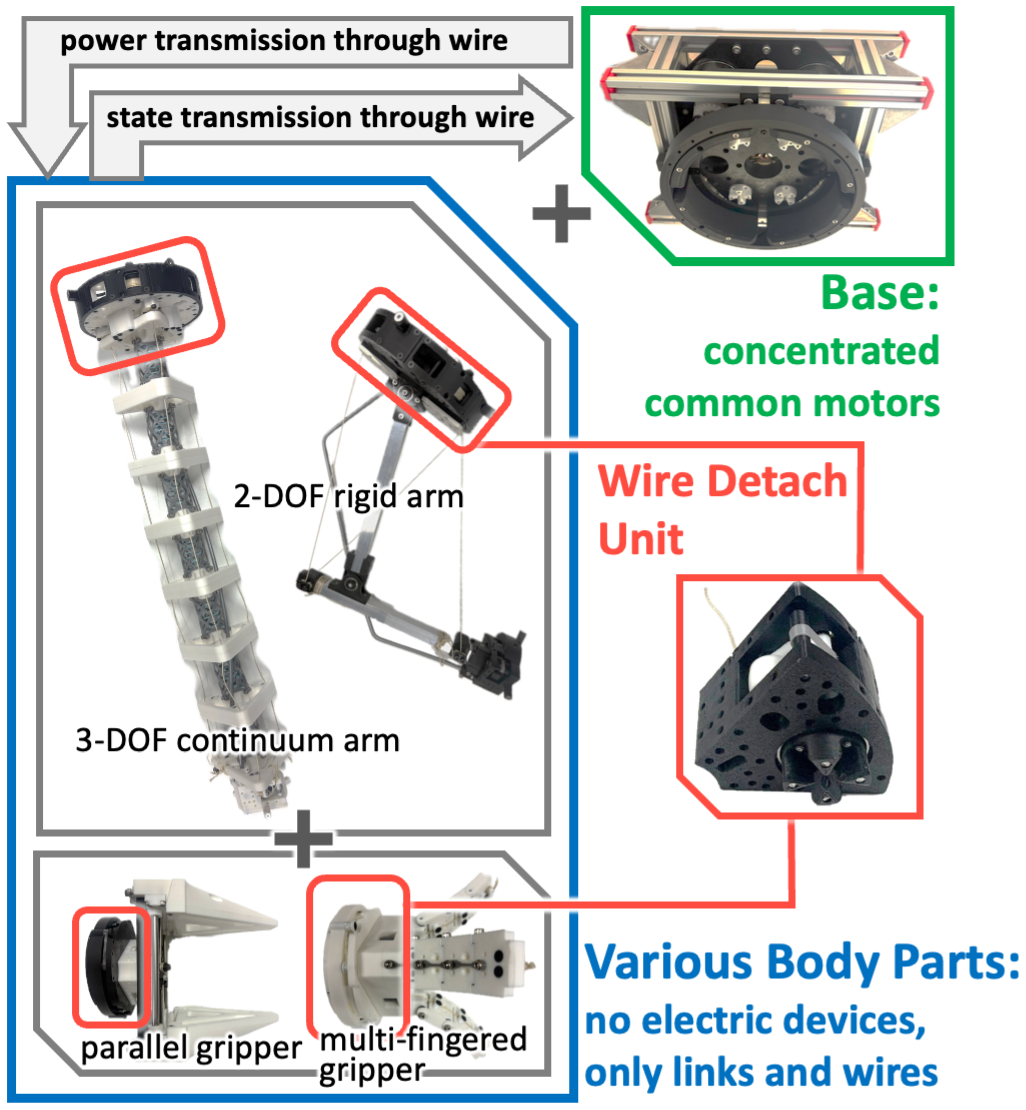
Detachable Wire Drive: Reconfigurable Robot Architecture with Shared Actuators
T. Hattori, K. Kawaharazuka, K. Okada
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2026), 2026
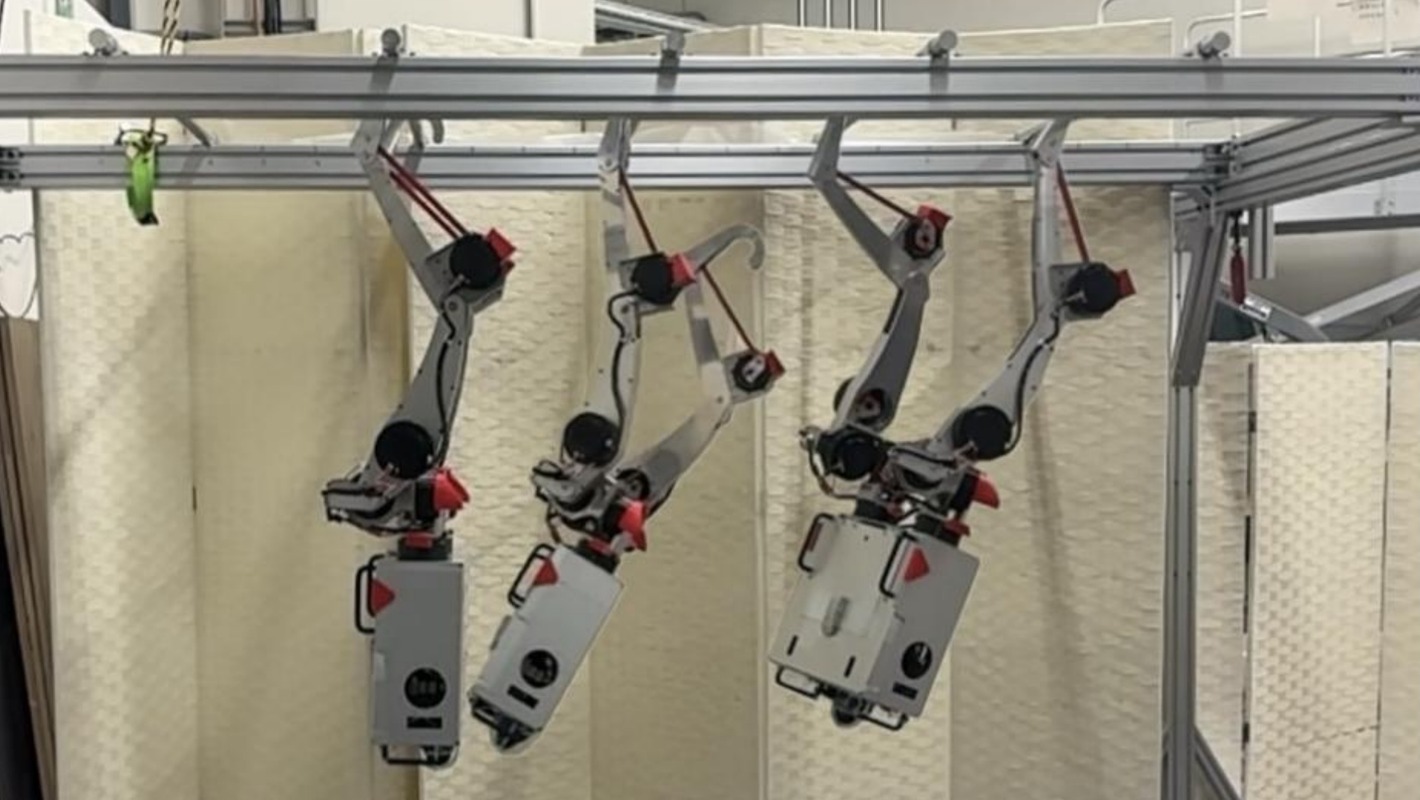
Robust Brachiation on a Life-Sized Dual-Arm Robot Using Waypoint-Guided Reinforcement Learning
A. Iwata, K. Kawaharazuka, K. Yoneda, T. Hattori, K. Okada
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2026), 2026
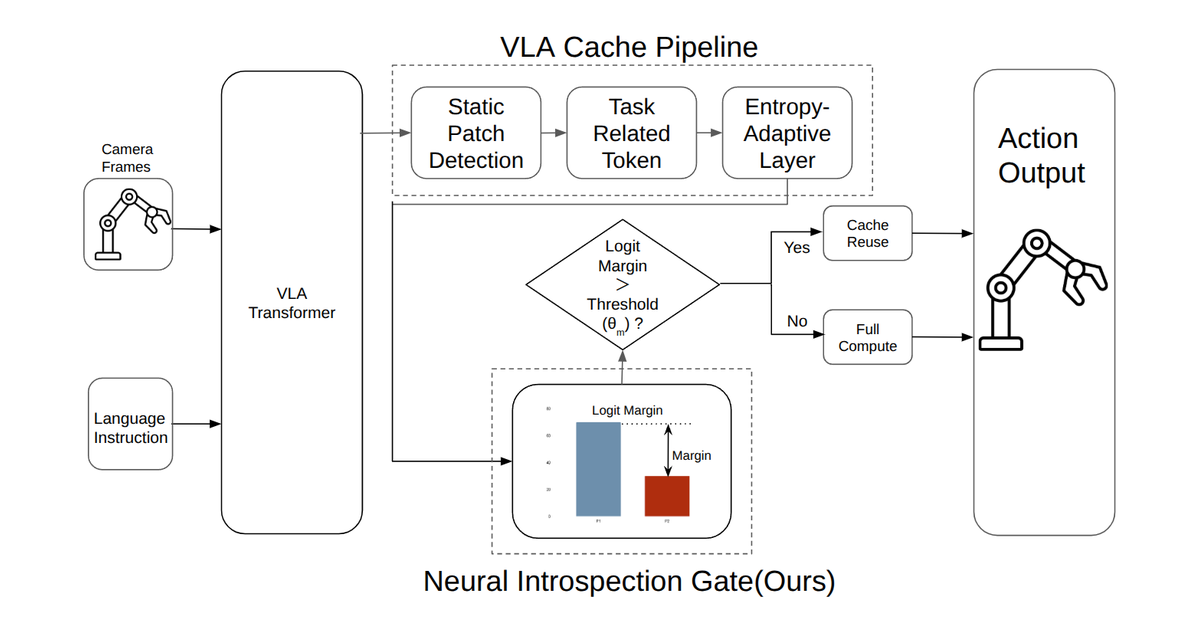
Neural Introspection Gating for Adaptive KV-Cache Reuse in Vision-Language-Action Models
Z. Wu, K. Kawaharazuka, K. Okada
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2026), 2026
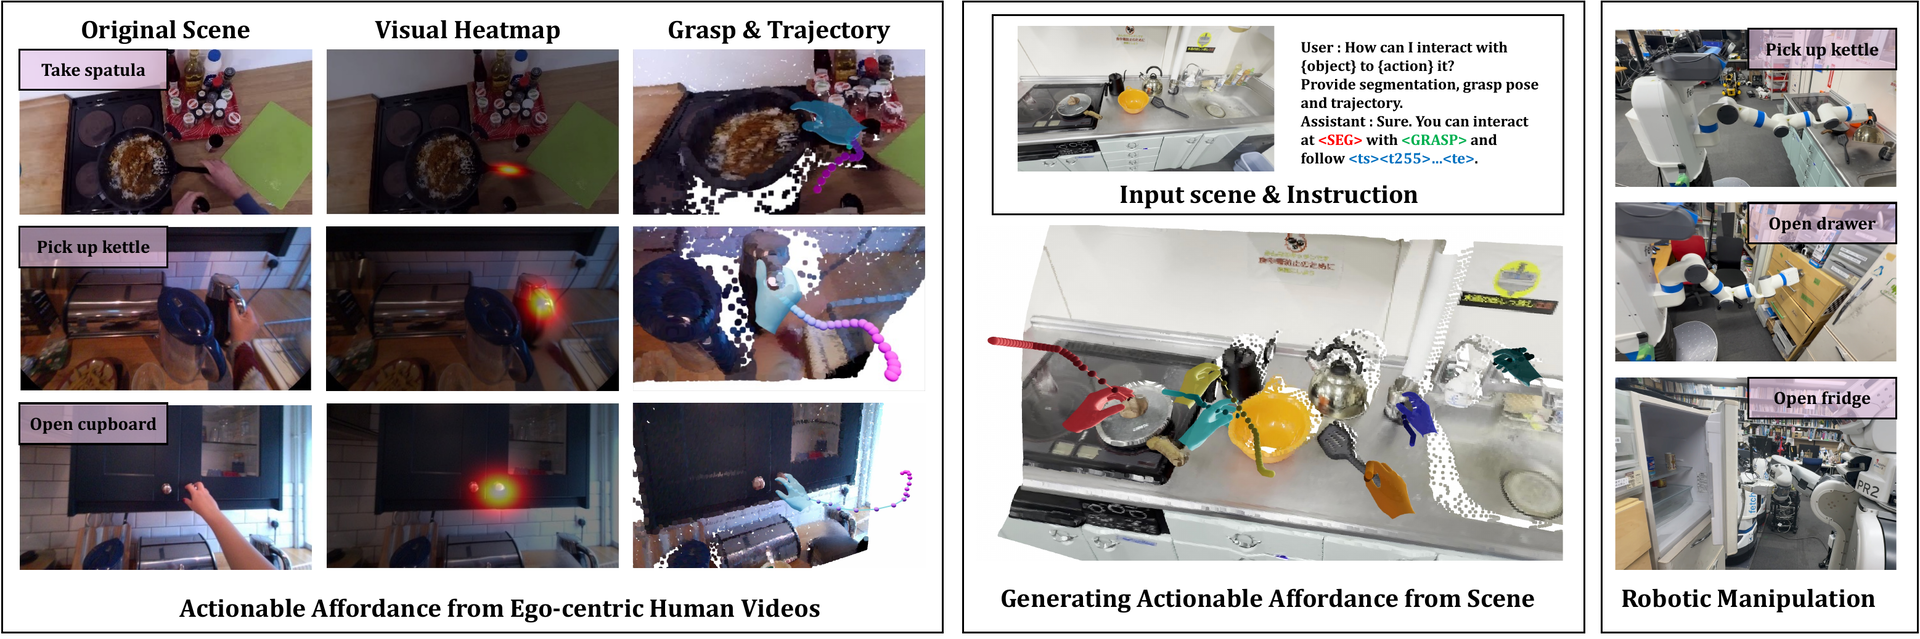
VLAff: Vision-Language-Affordance Model for Unified Actionable Affordances
J. Oh, K. Kawaharazuka, K. Okada
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2026), 2026
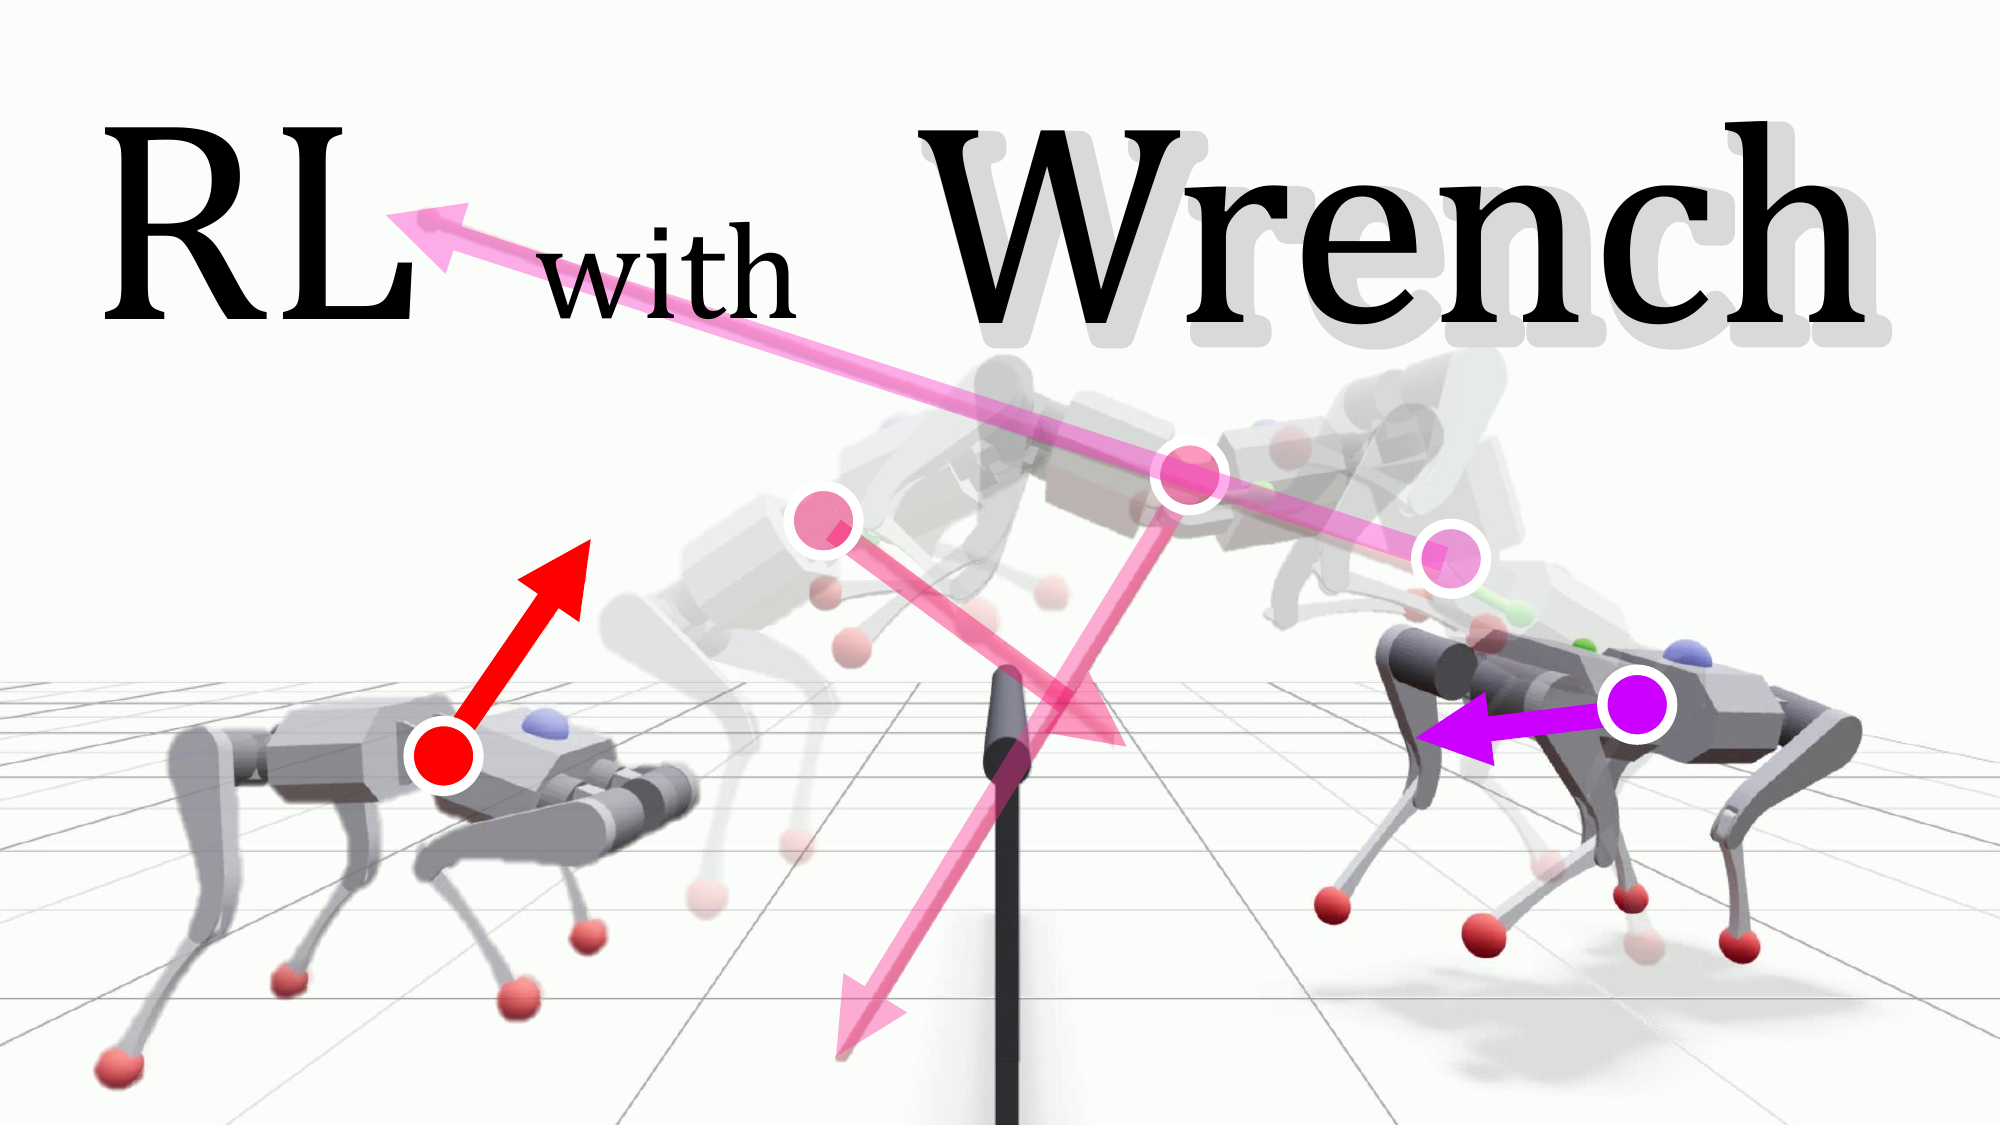
WARL: Wrench-Augmented Reinforcement Learning for Task-Agnostic Learning in Legged Robots
K. Yoneda, K. Kawaharazuka, K. Okada
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2026), 2026
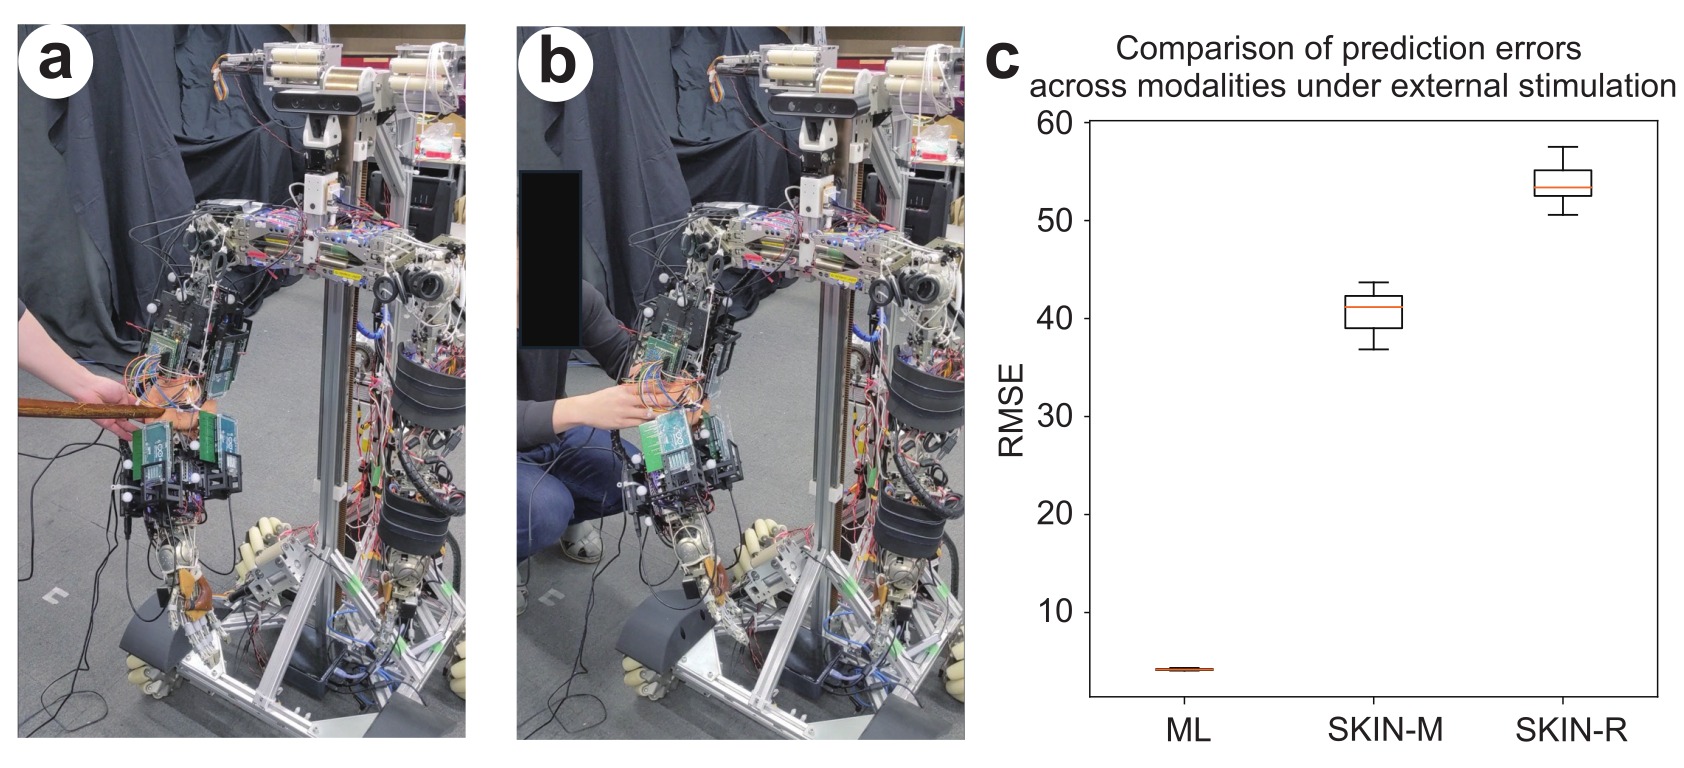
Design of a Biomimetic Joint-Covering Skin with Tissue-Like Structure to Enhance Proprioception in a Musculoskeletal Humanoid
A. Miki, S. Hasegawa, Y. Ribayashi, K. Kawaharazuka, K. Okada
2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2026), 2026
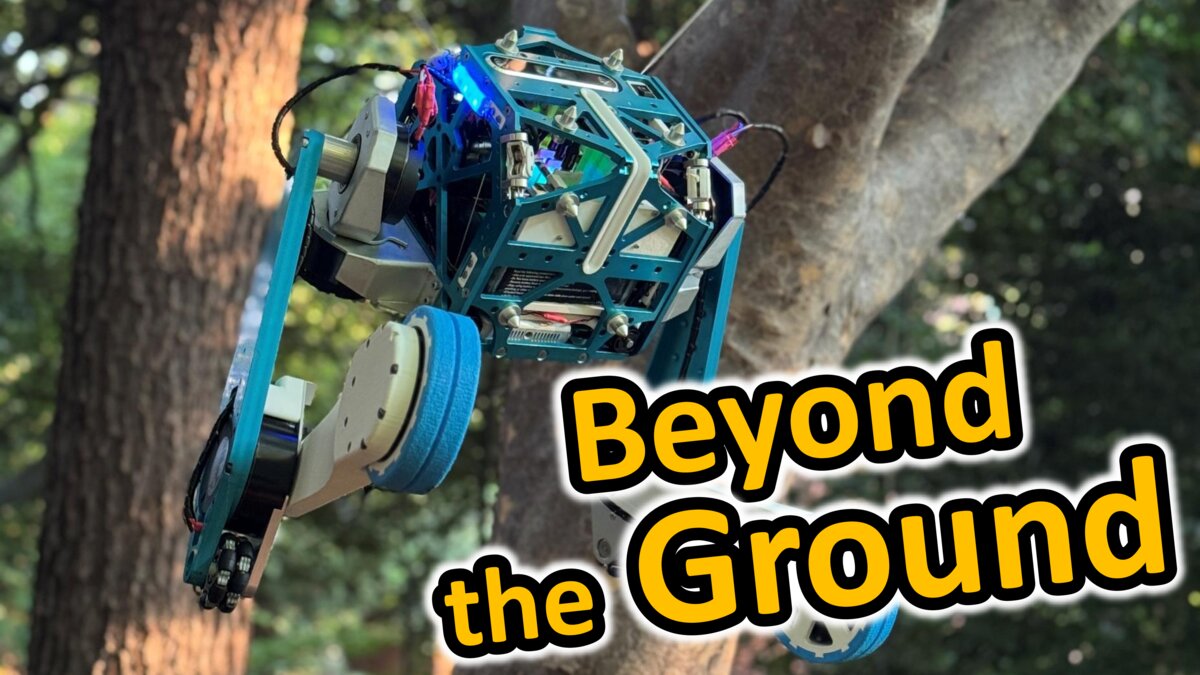
WiXus: A Wheeled-Legged Robot with Wire-Driven Environmental Utilizing to Integrate Mobility and Manipulation
S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Okada
2026 IEEE International Conference on Robotics and Automation (ICRA2026), 2026
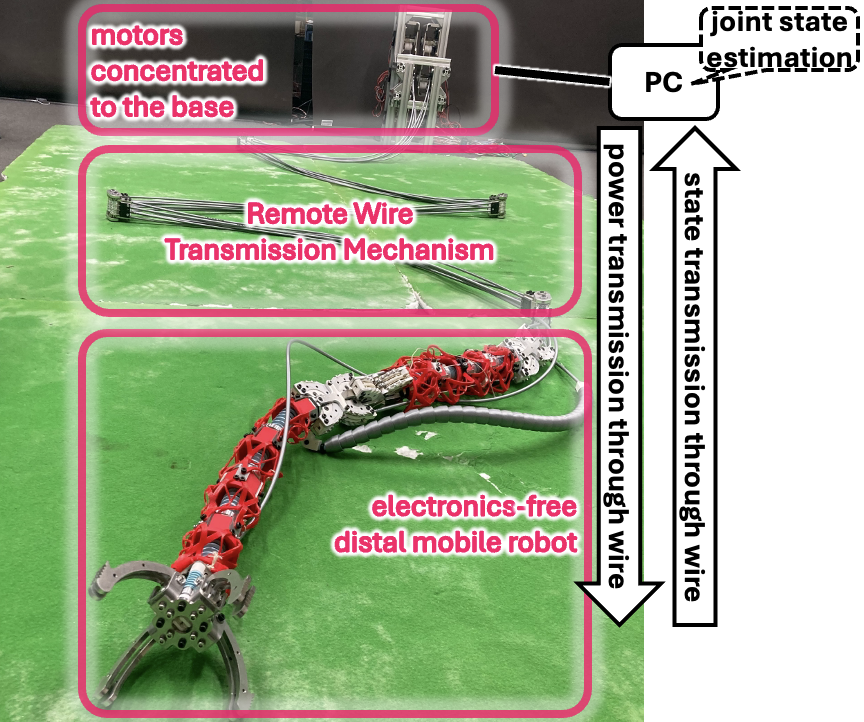
REWW-ARM - Remote Wire-Driven Mobile Robot: Design, Control, and Experimental Validation
T. Hattori, K. Kawaharazuka, T. Suzuki, K. Yoneda, K. Okada
Advanced Intelligent Systems (AISY), 2025
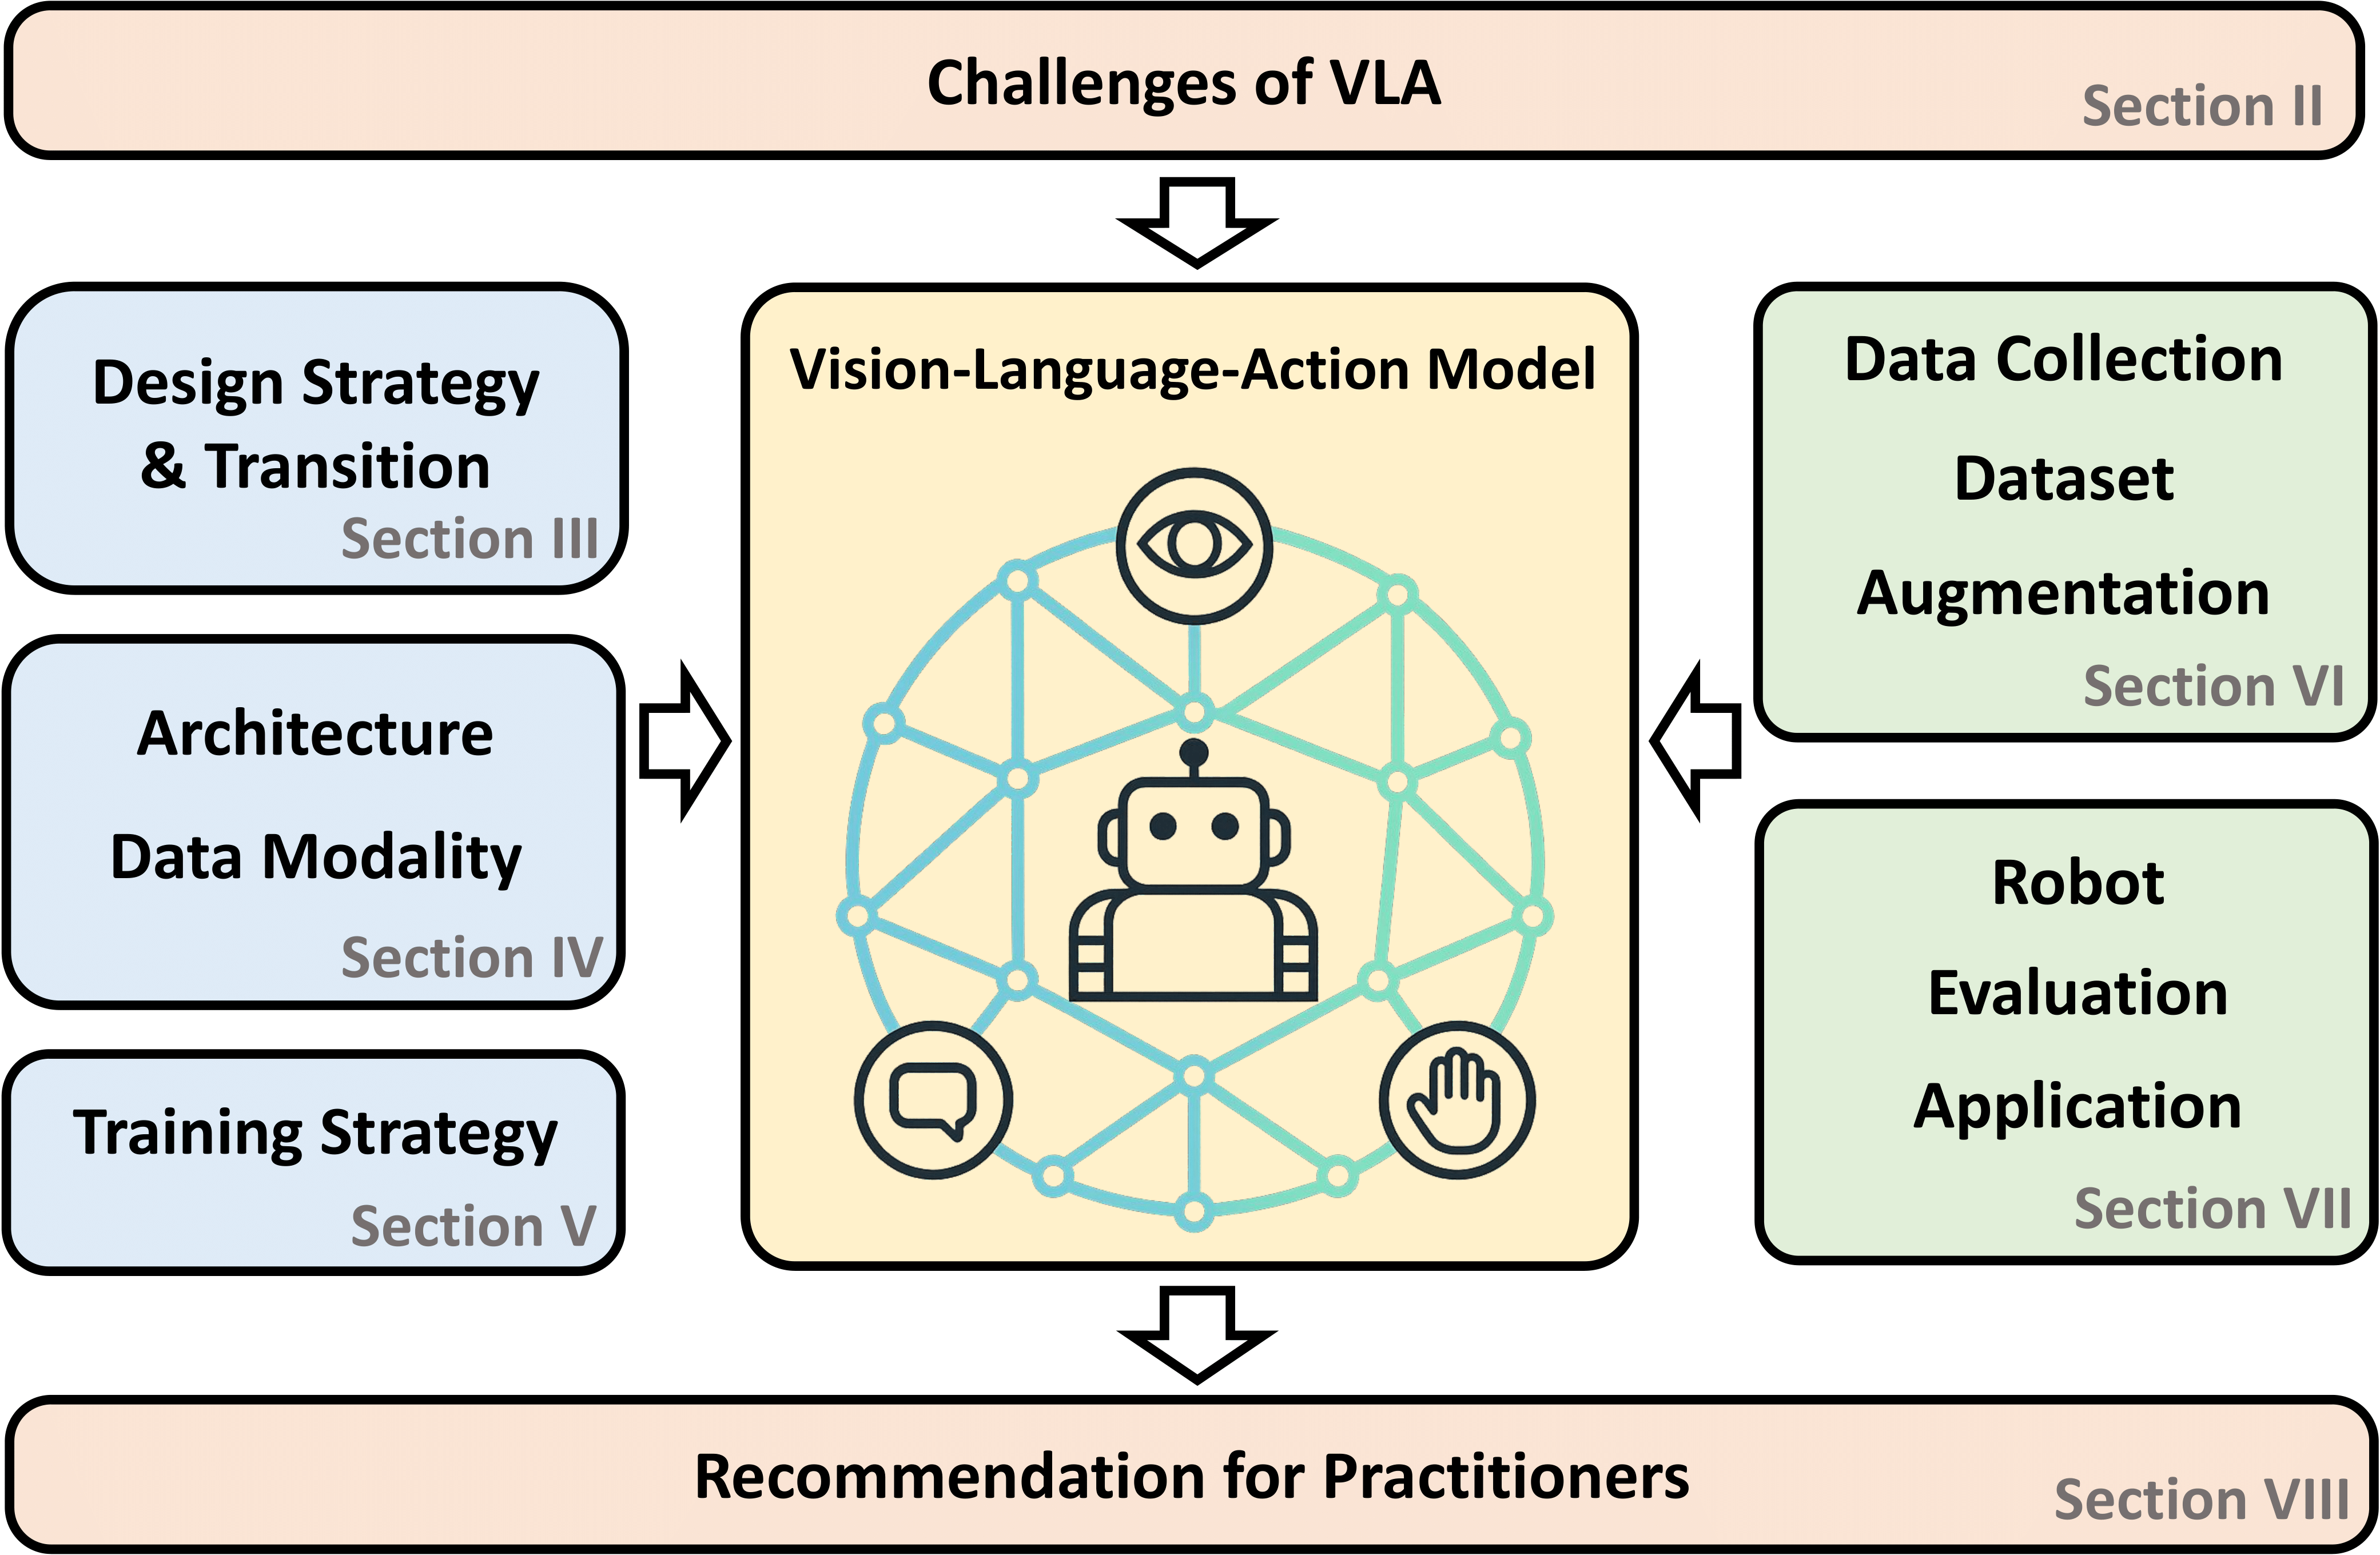
Vision-Language-Action Models for Robotics: A Review Towards Real-World Applications
K. Kawaharazuka, J. Oh, J. Yamada, I. Posner, Y. Zhu
IEEE Access, 2025
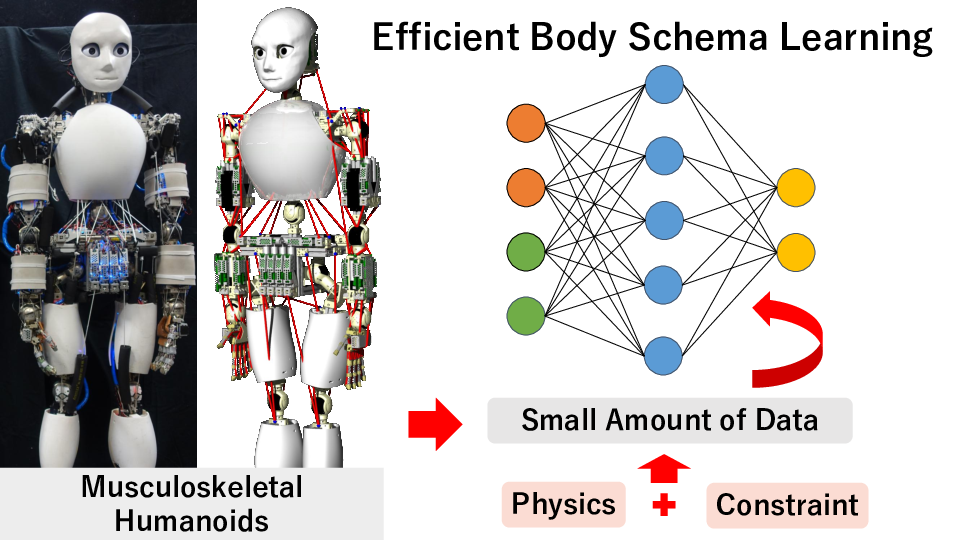
PIMBS: Efficient Body Schema Learning for Musculoskeletal Humanoids with Physics-Informed Neural Networks
K. Kawaharazuka, T. Hattori, K. Yoneda, K. Okada
IEEE Robotics and Automation Letters (RAL), 2025
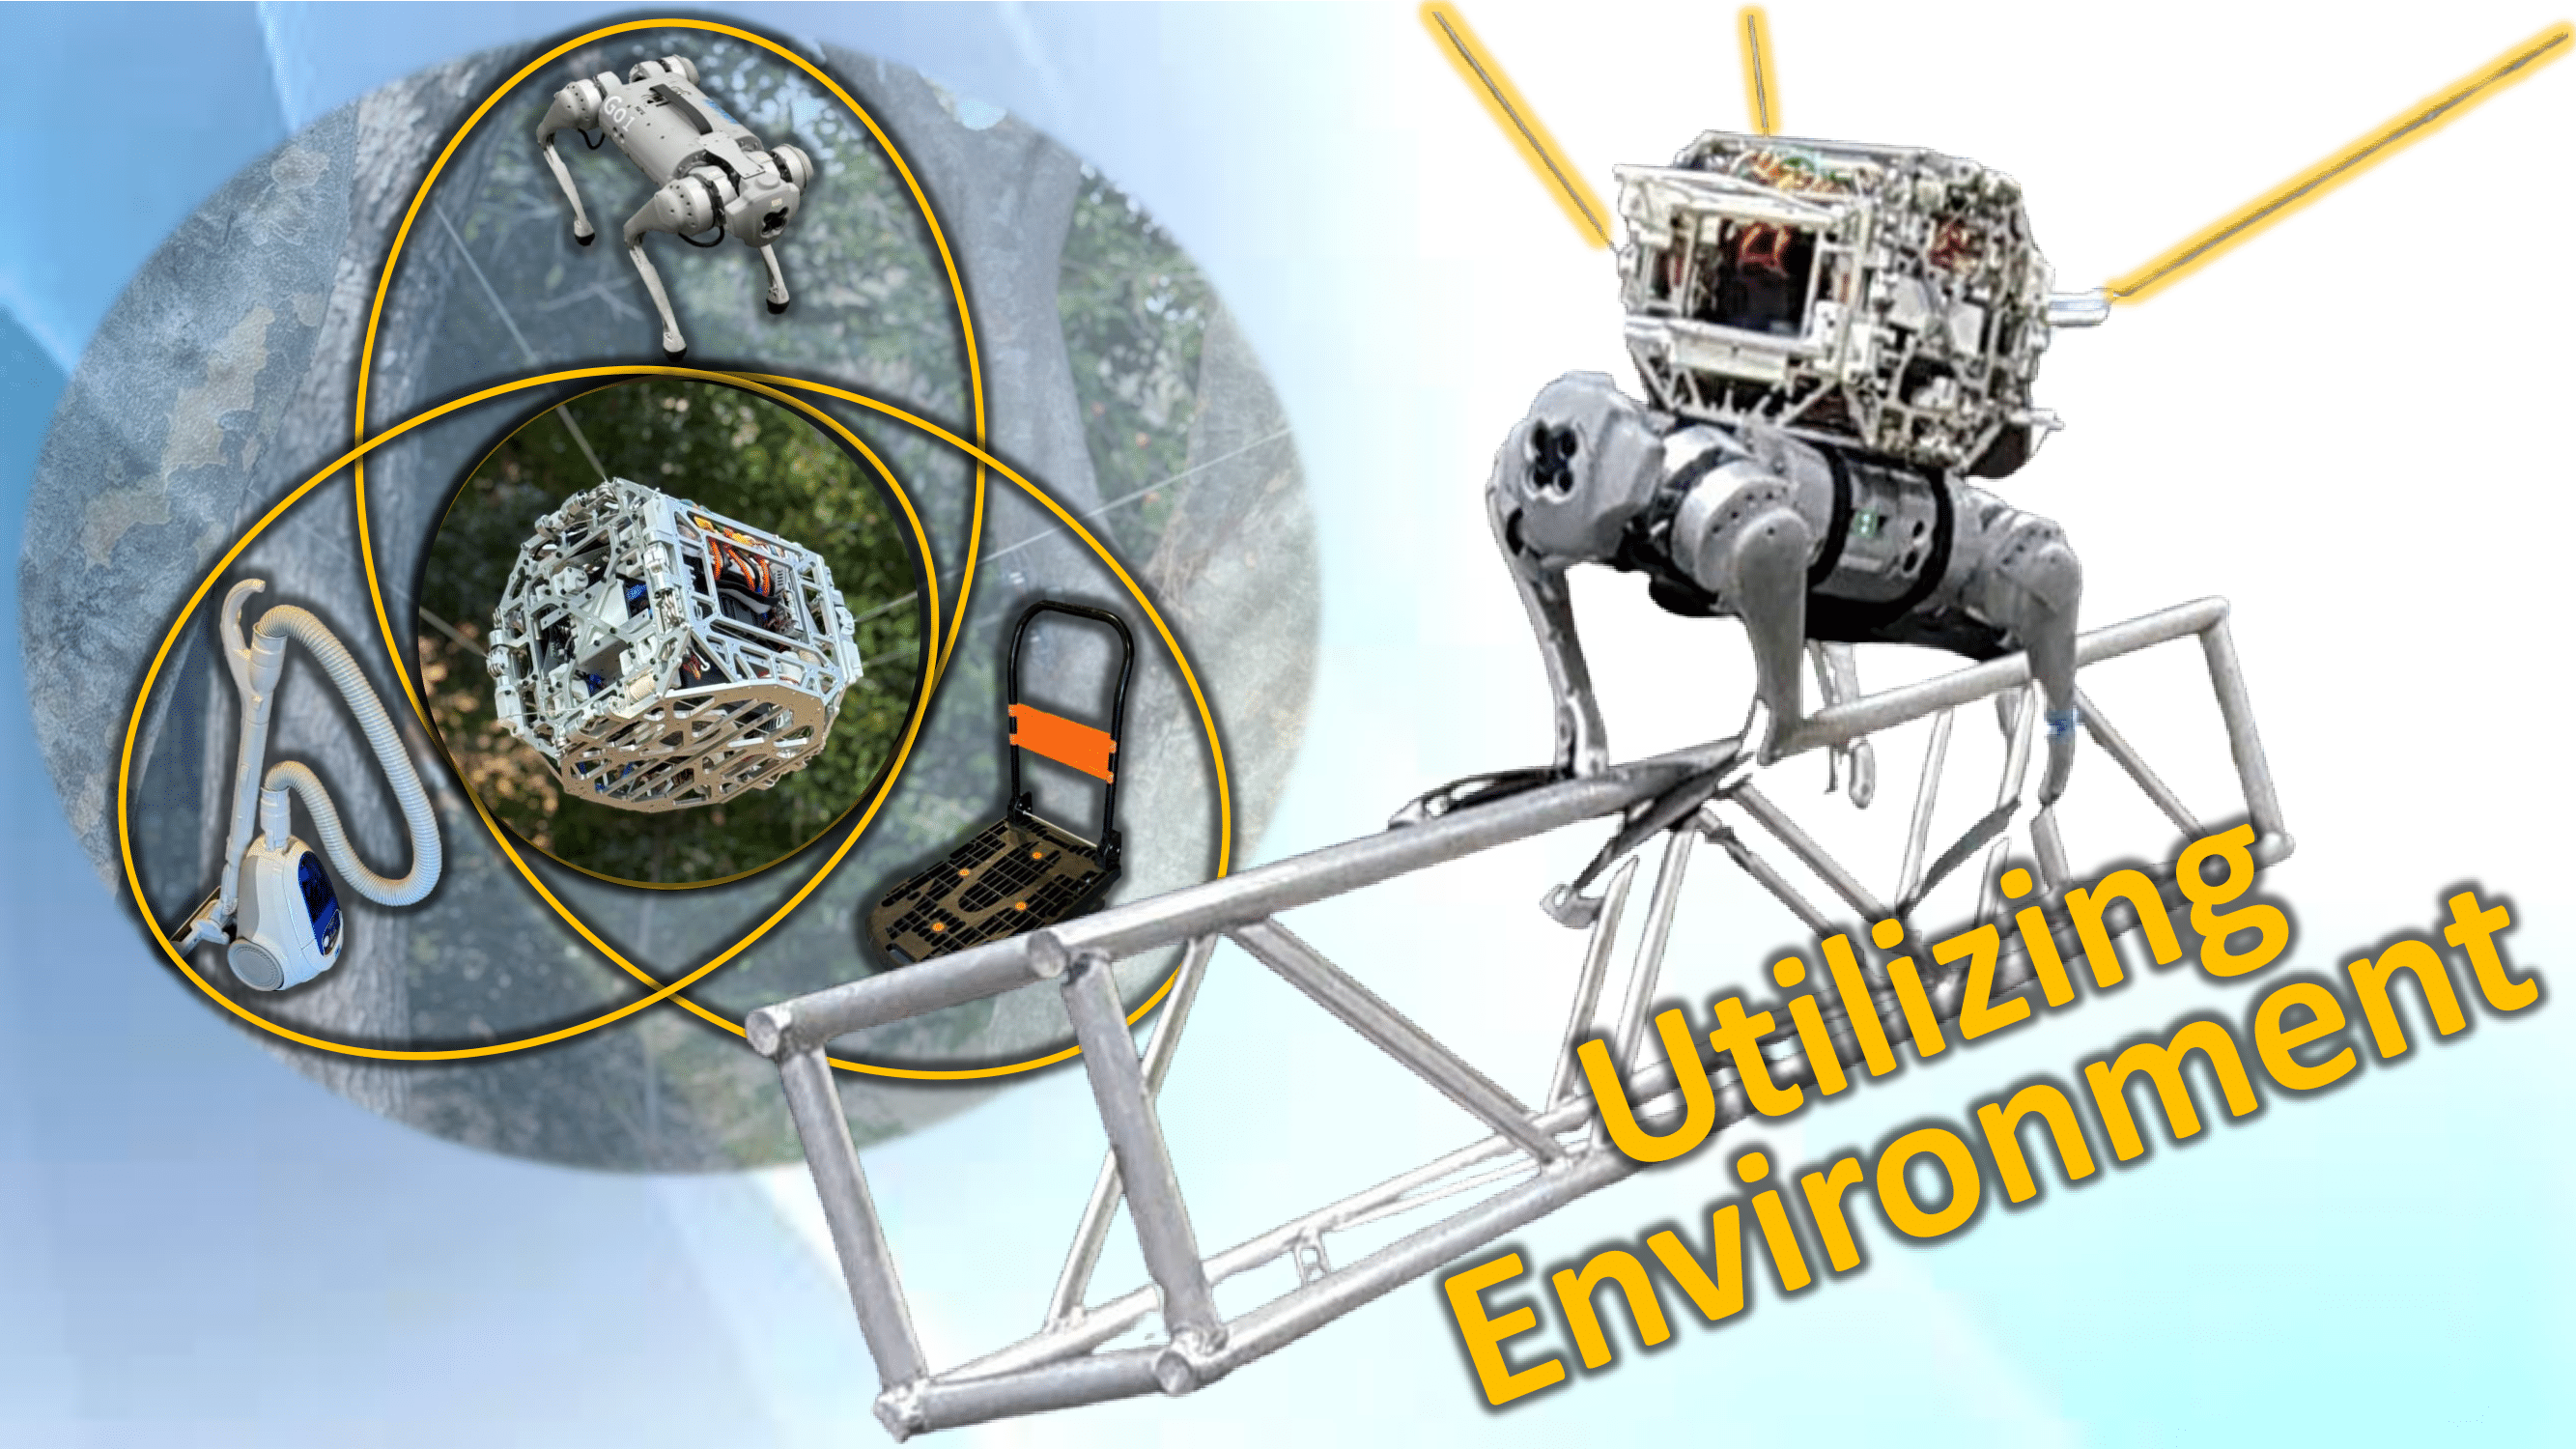
Overcoming Physical Limitations Utilizing the Surrounding Environment with a Wire-Driven Multipurpose Robot
S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Okada, M. Inaba
Advanced Robotics Research (ADRR), 2025
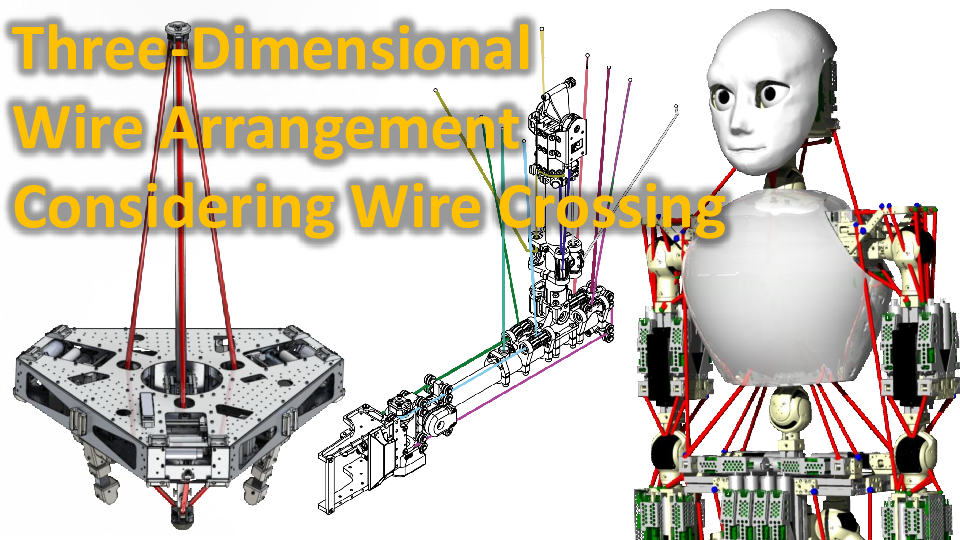
Design Optimization of Three-Dimensional Wire Arrangement Considering Wire Crossings for Tendon-driven Robots
K. Kawaharazuka, S. Inoue, Y. Sahara, K. Yoneda, T. Suzuki, K. Okada
2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2025), 2025
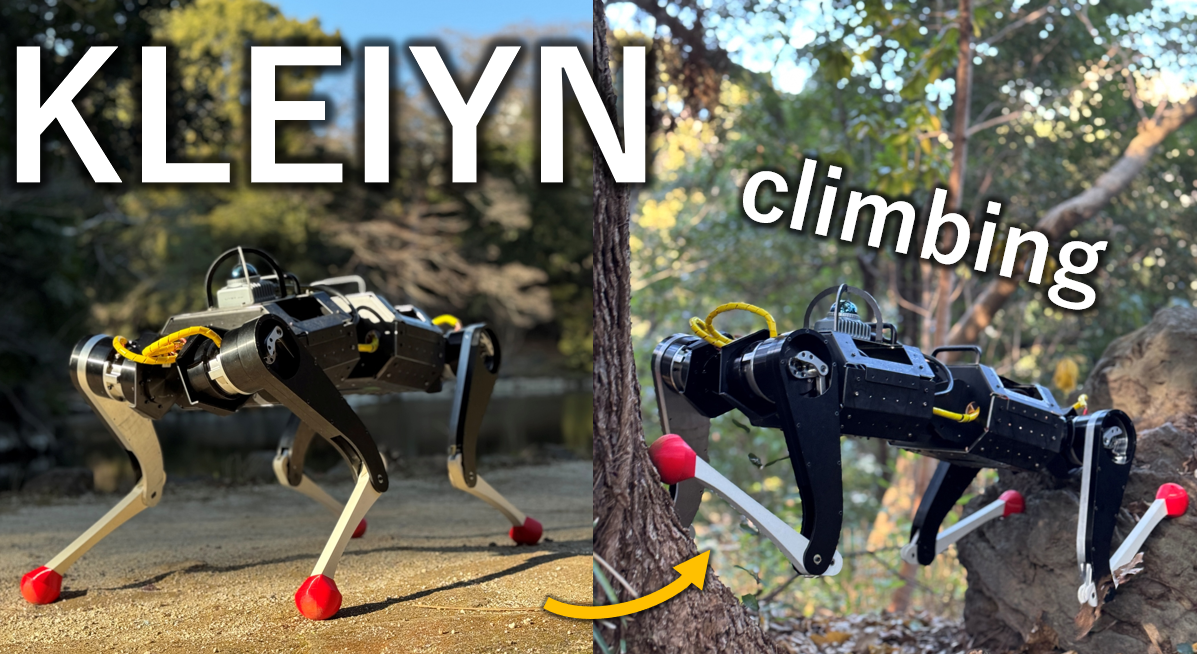
KLEIYN : A Quadruped Robot with an Active Waist for Both Locomotion and Wall Climbing
K. Yoneda, K. Kawaharazuka, T. Suzuki, T. Hattori, K. Okada
2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2025), 2025
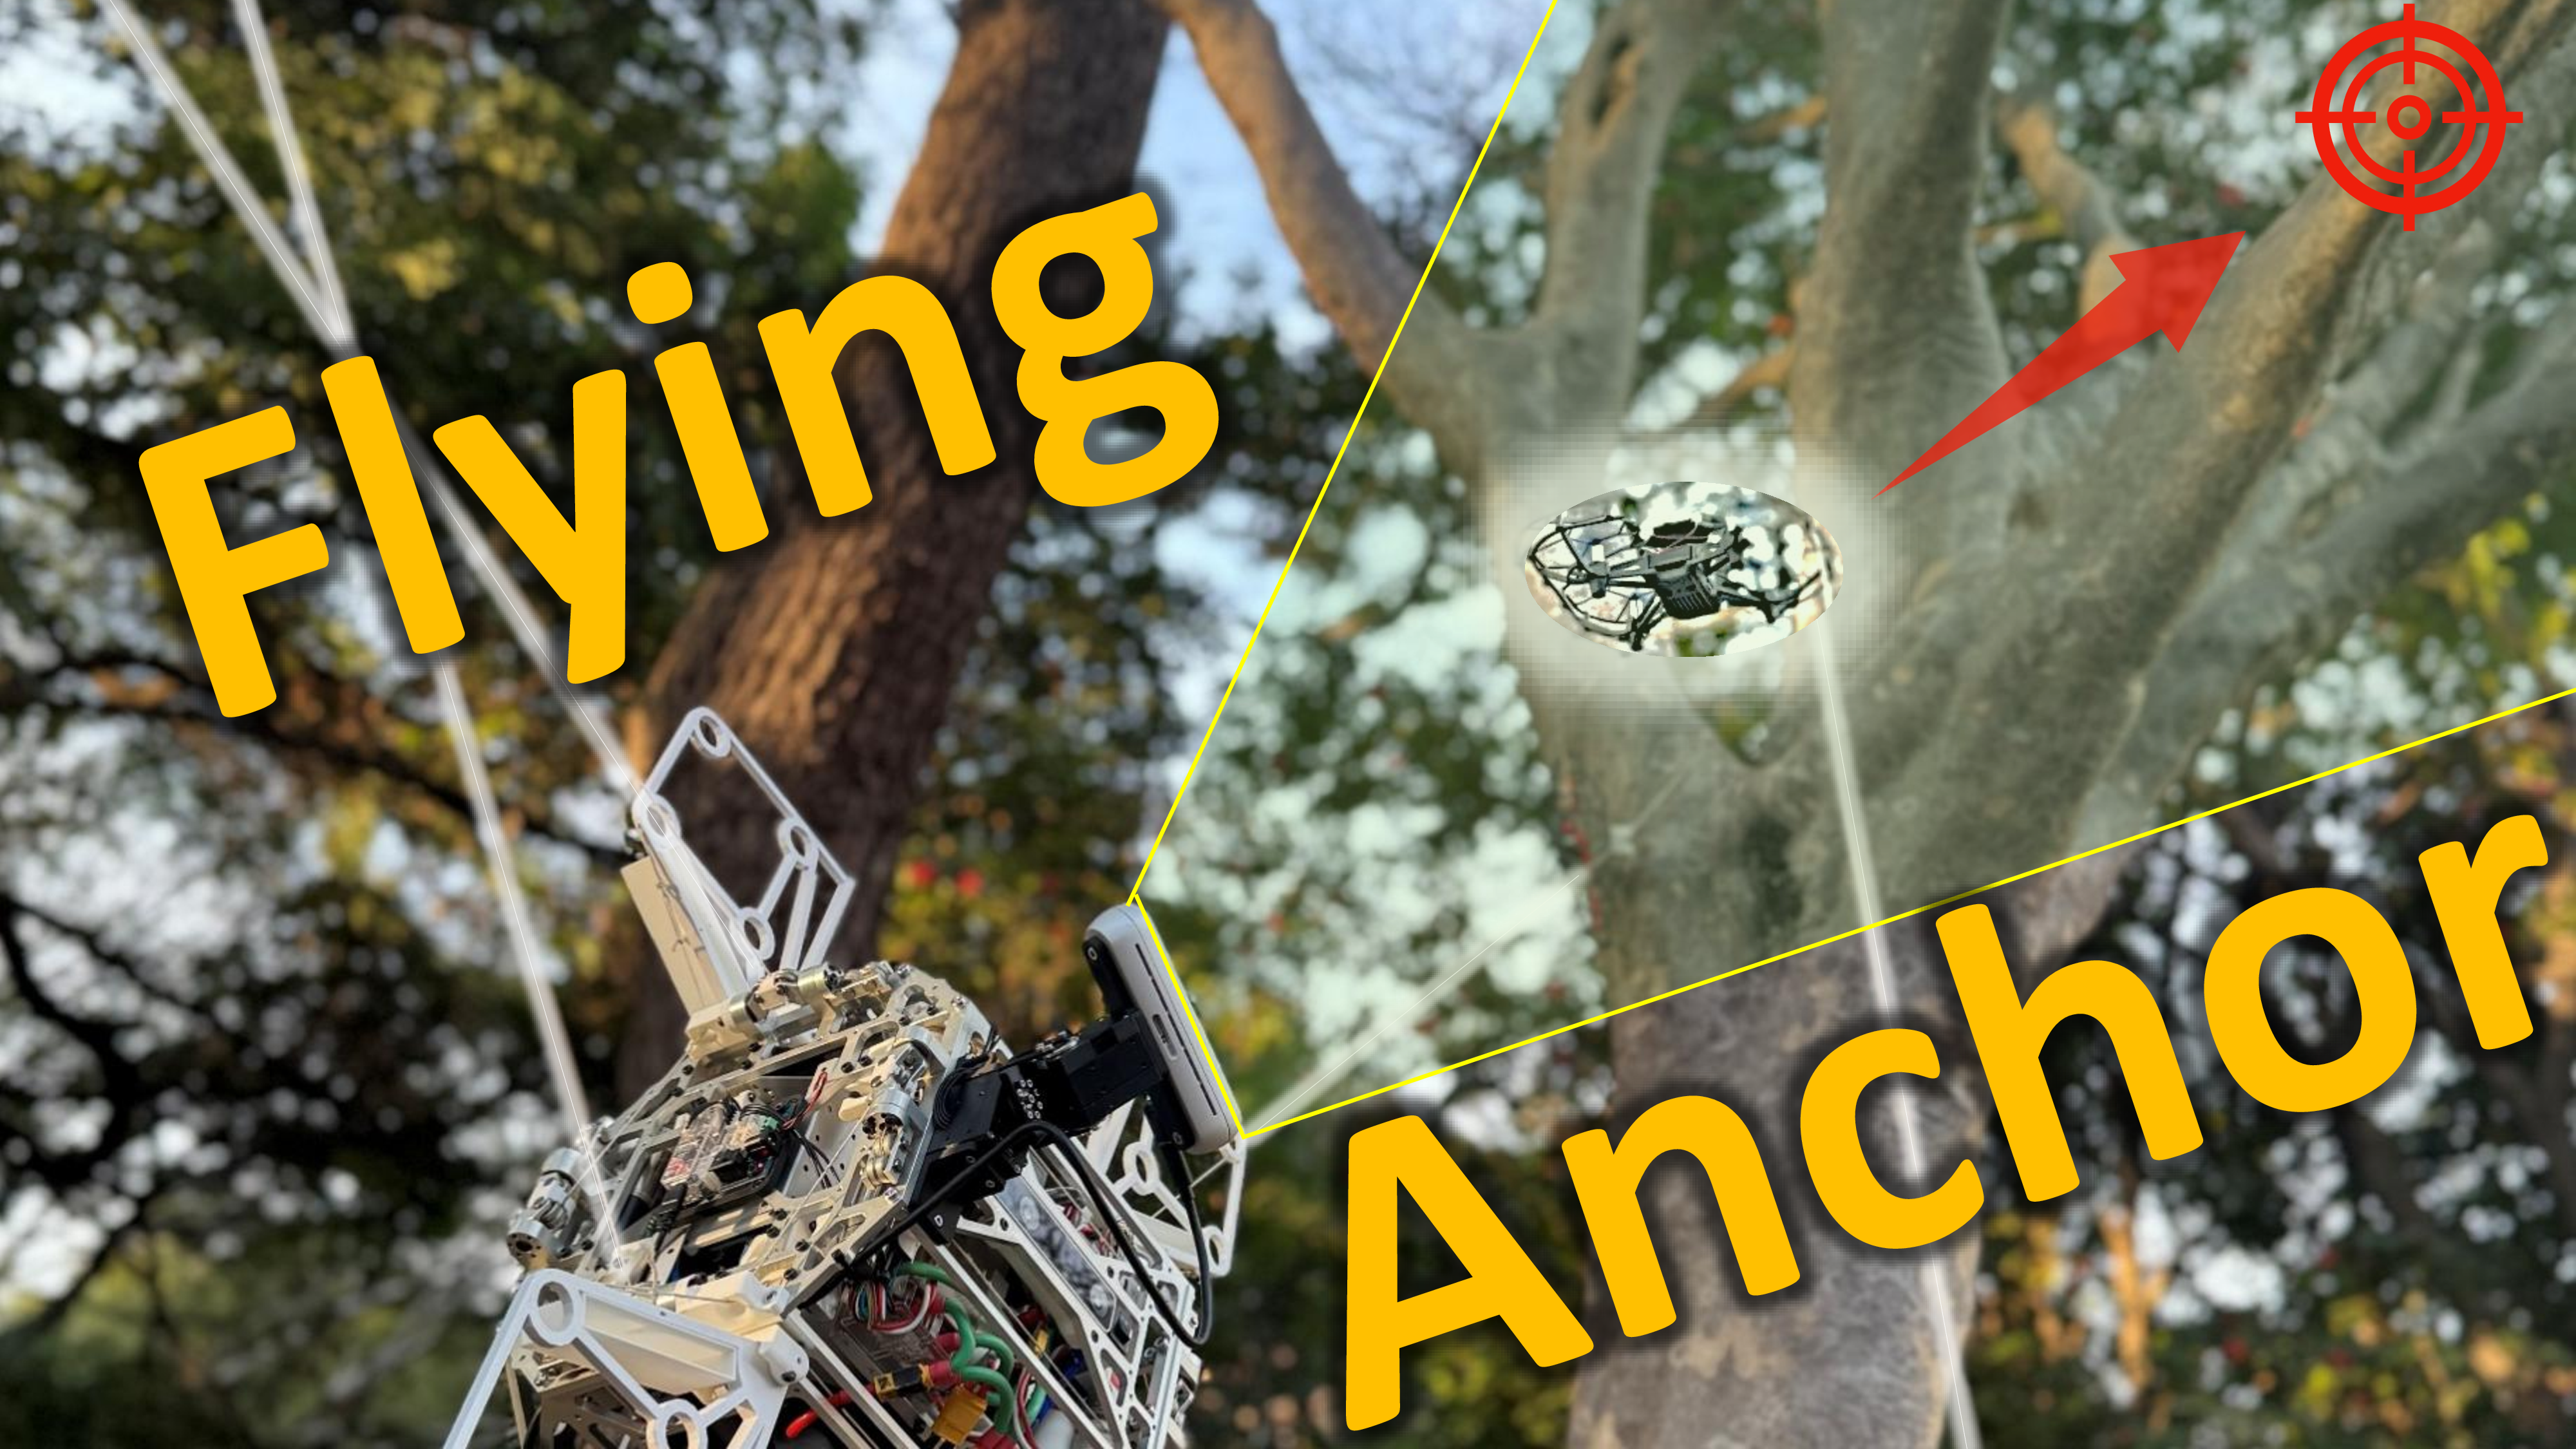
An RGB-D Camera-Based Multi-Small Flying Anchors Control for Wire-Driven Robots Connecting to the Environment
S. Inoue, K. Kawaharazuka, K. Yoneda, S. Yuzaki, Y. Sahara, T. Suzuki, K. Okada
2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2025), 2025
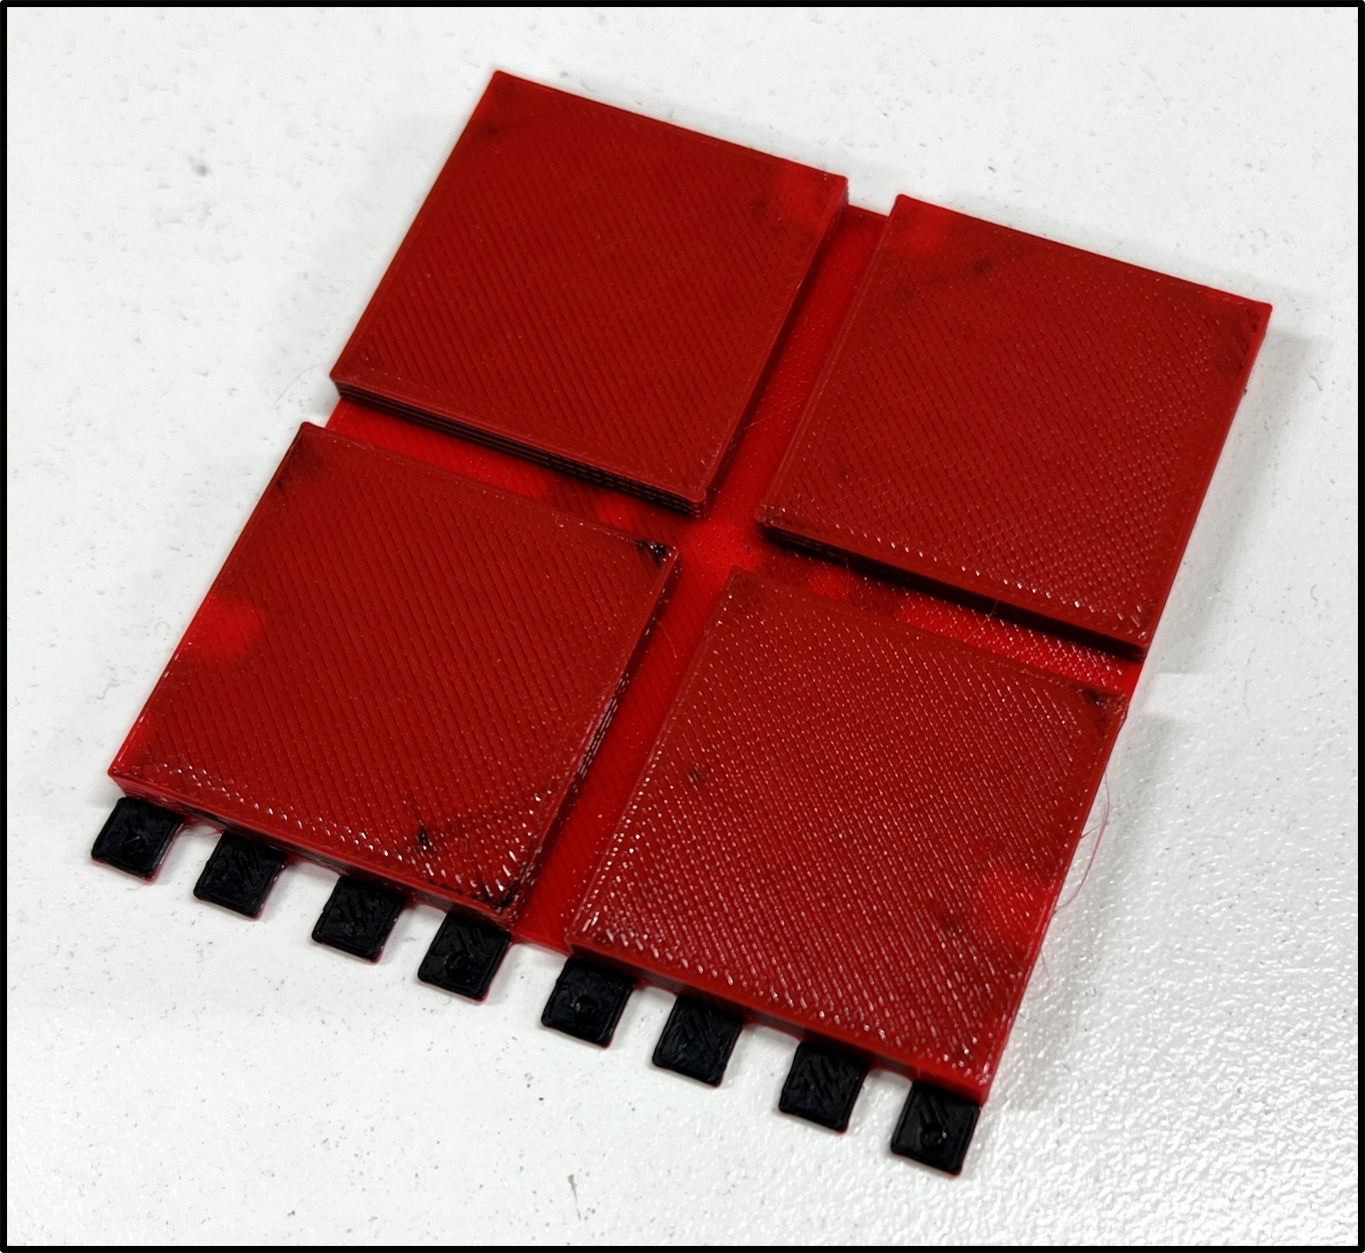
M3D-skin: Multi-material 3D-printed Tactile Sensor with Hierarchical Infill Structures for Pressure Sensing
S. Yoshimura, K. Kawaharazuka, K. Okada
2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2025), 2025
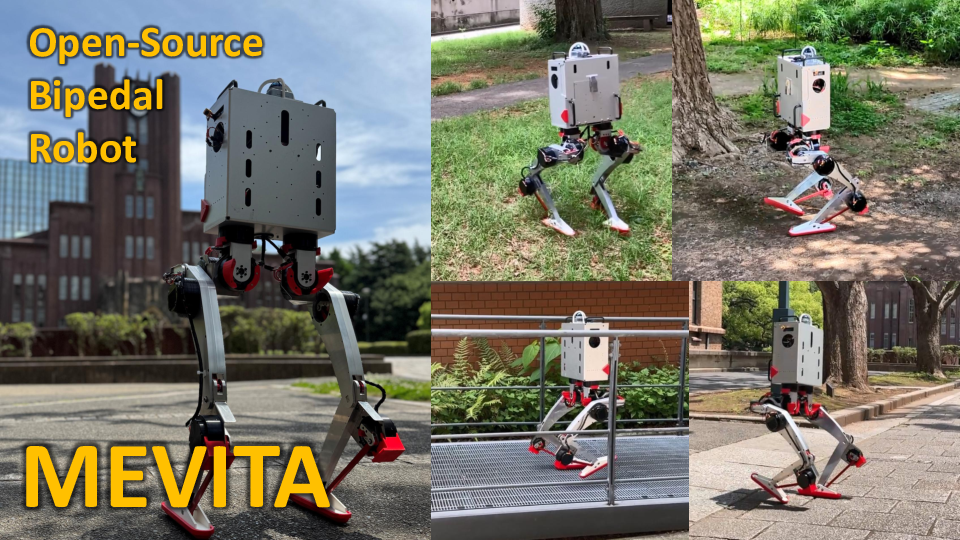
MEVITA: Open-Source Bipedal Robot Assembled from E-Commerce Components via Sheet Metal Welding
K. Kawaharazuka, S. Sawaguchi, A. Iwata, K. Yoneda, T. Suzuki, K. Okada
2025 IEEE-RAS International Conference on Humanoid Robots (HUMANOIDS2025), 2025
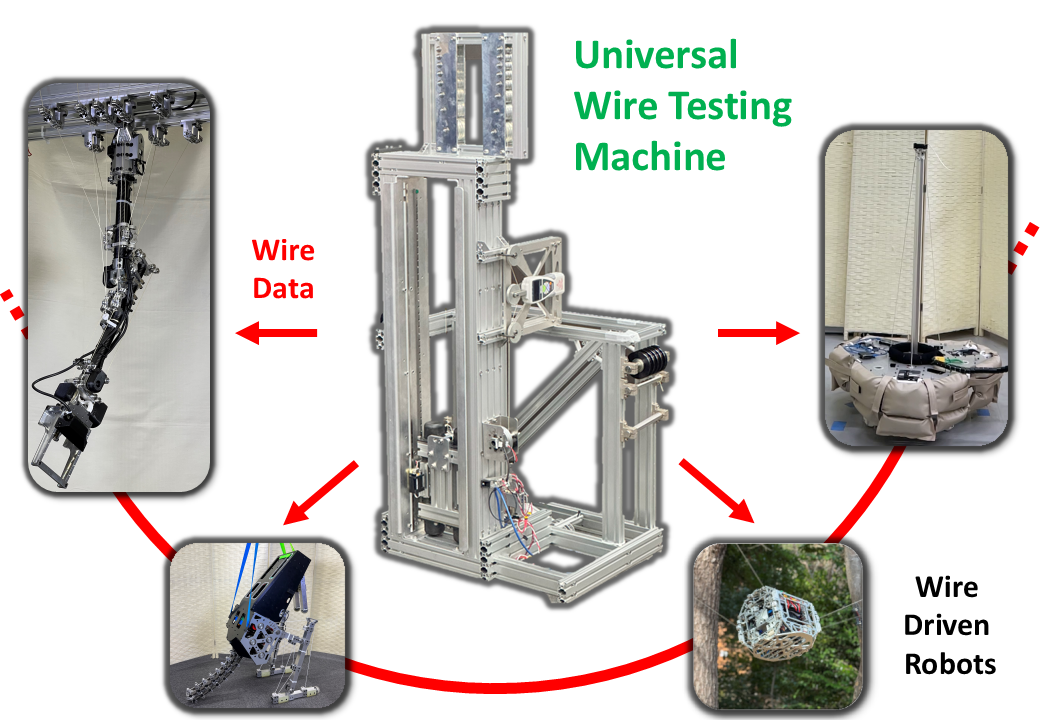
A Universal Wire Testing Machine for Enhancing the Performance of Wire-Driven Robots
T. Suzuki, K. Kawaharazuka, K. Okada
2025 IEEE-RAS International Conference on Humanoid Robots (HUMANOIDS2025), 2025
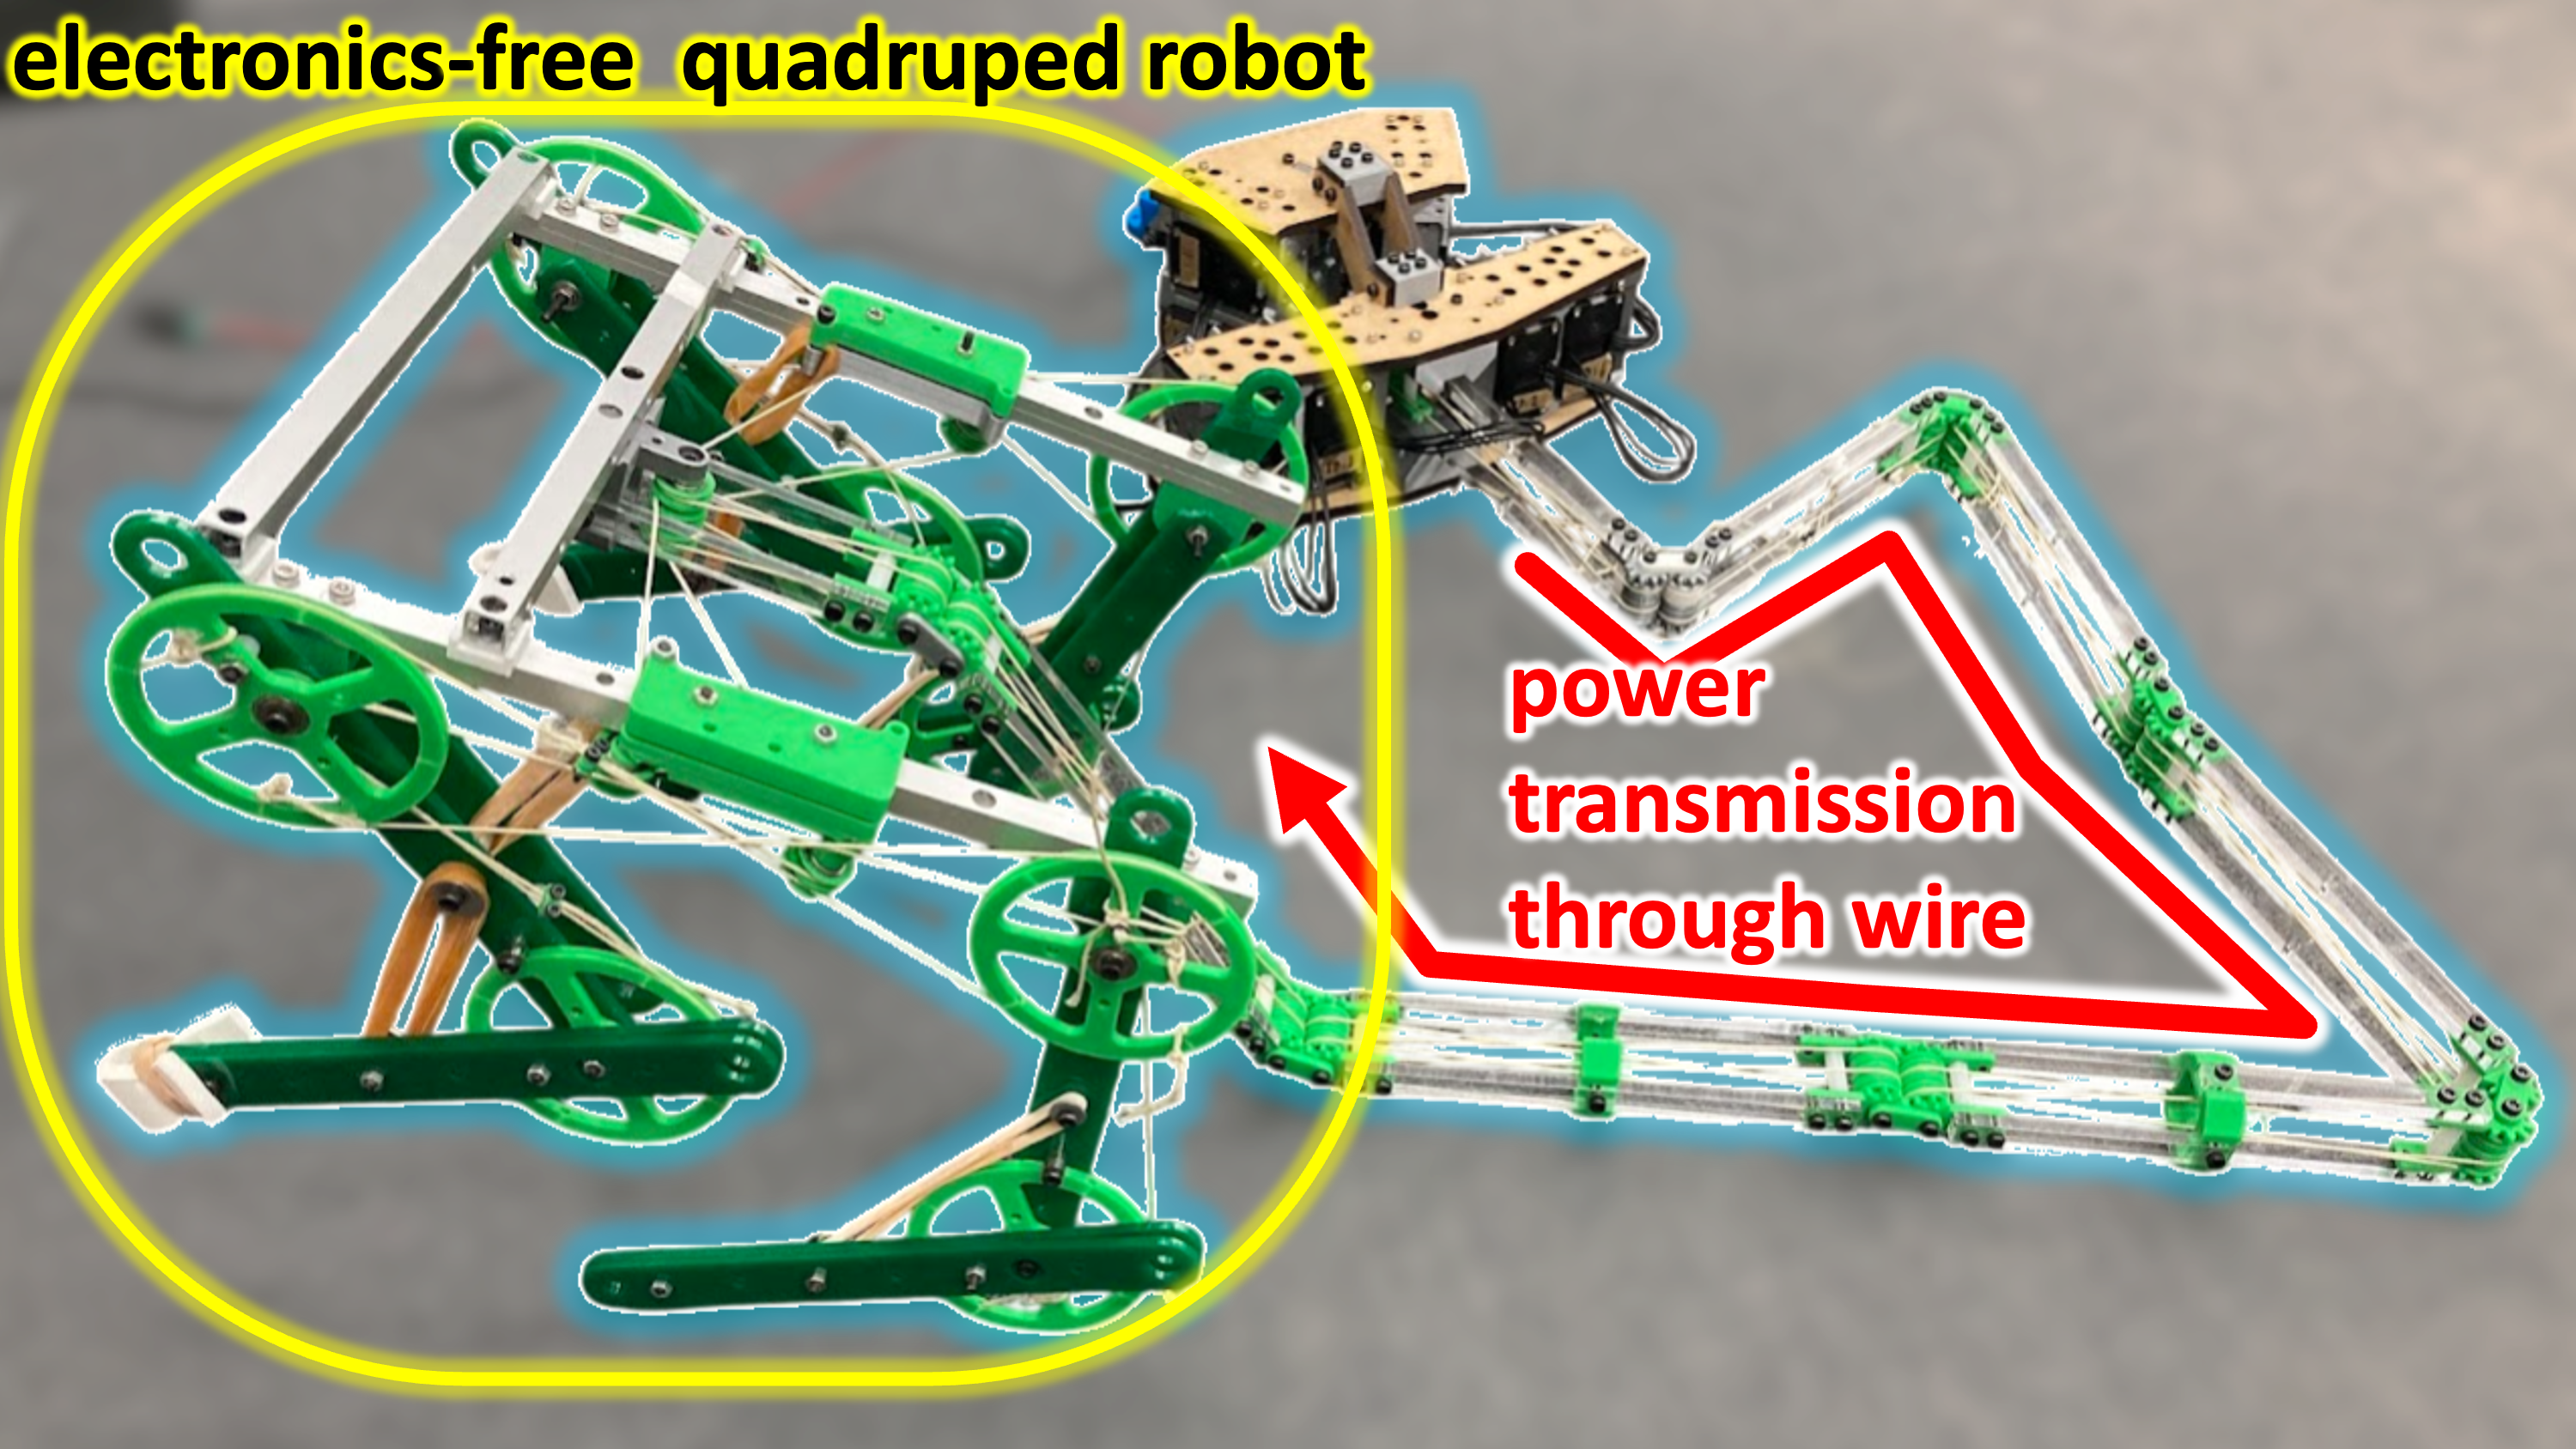
Design and Development of a Remotely Wire-Driven Walking Robot
T. Hattori, K. Kawaharazuka, K. Okada
2025 IEEE-RAS International Conference on Humanoid Robots (HUMANOIDS2025), 2025
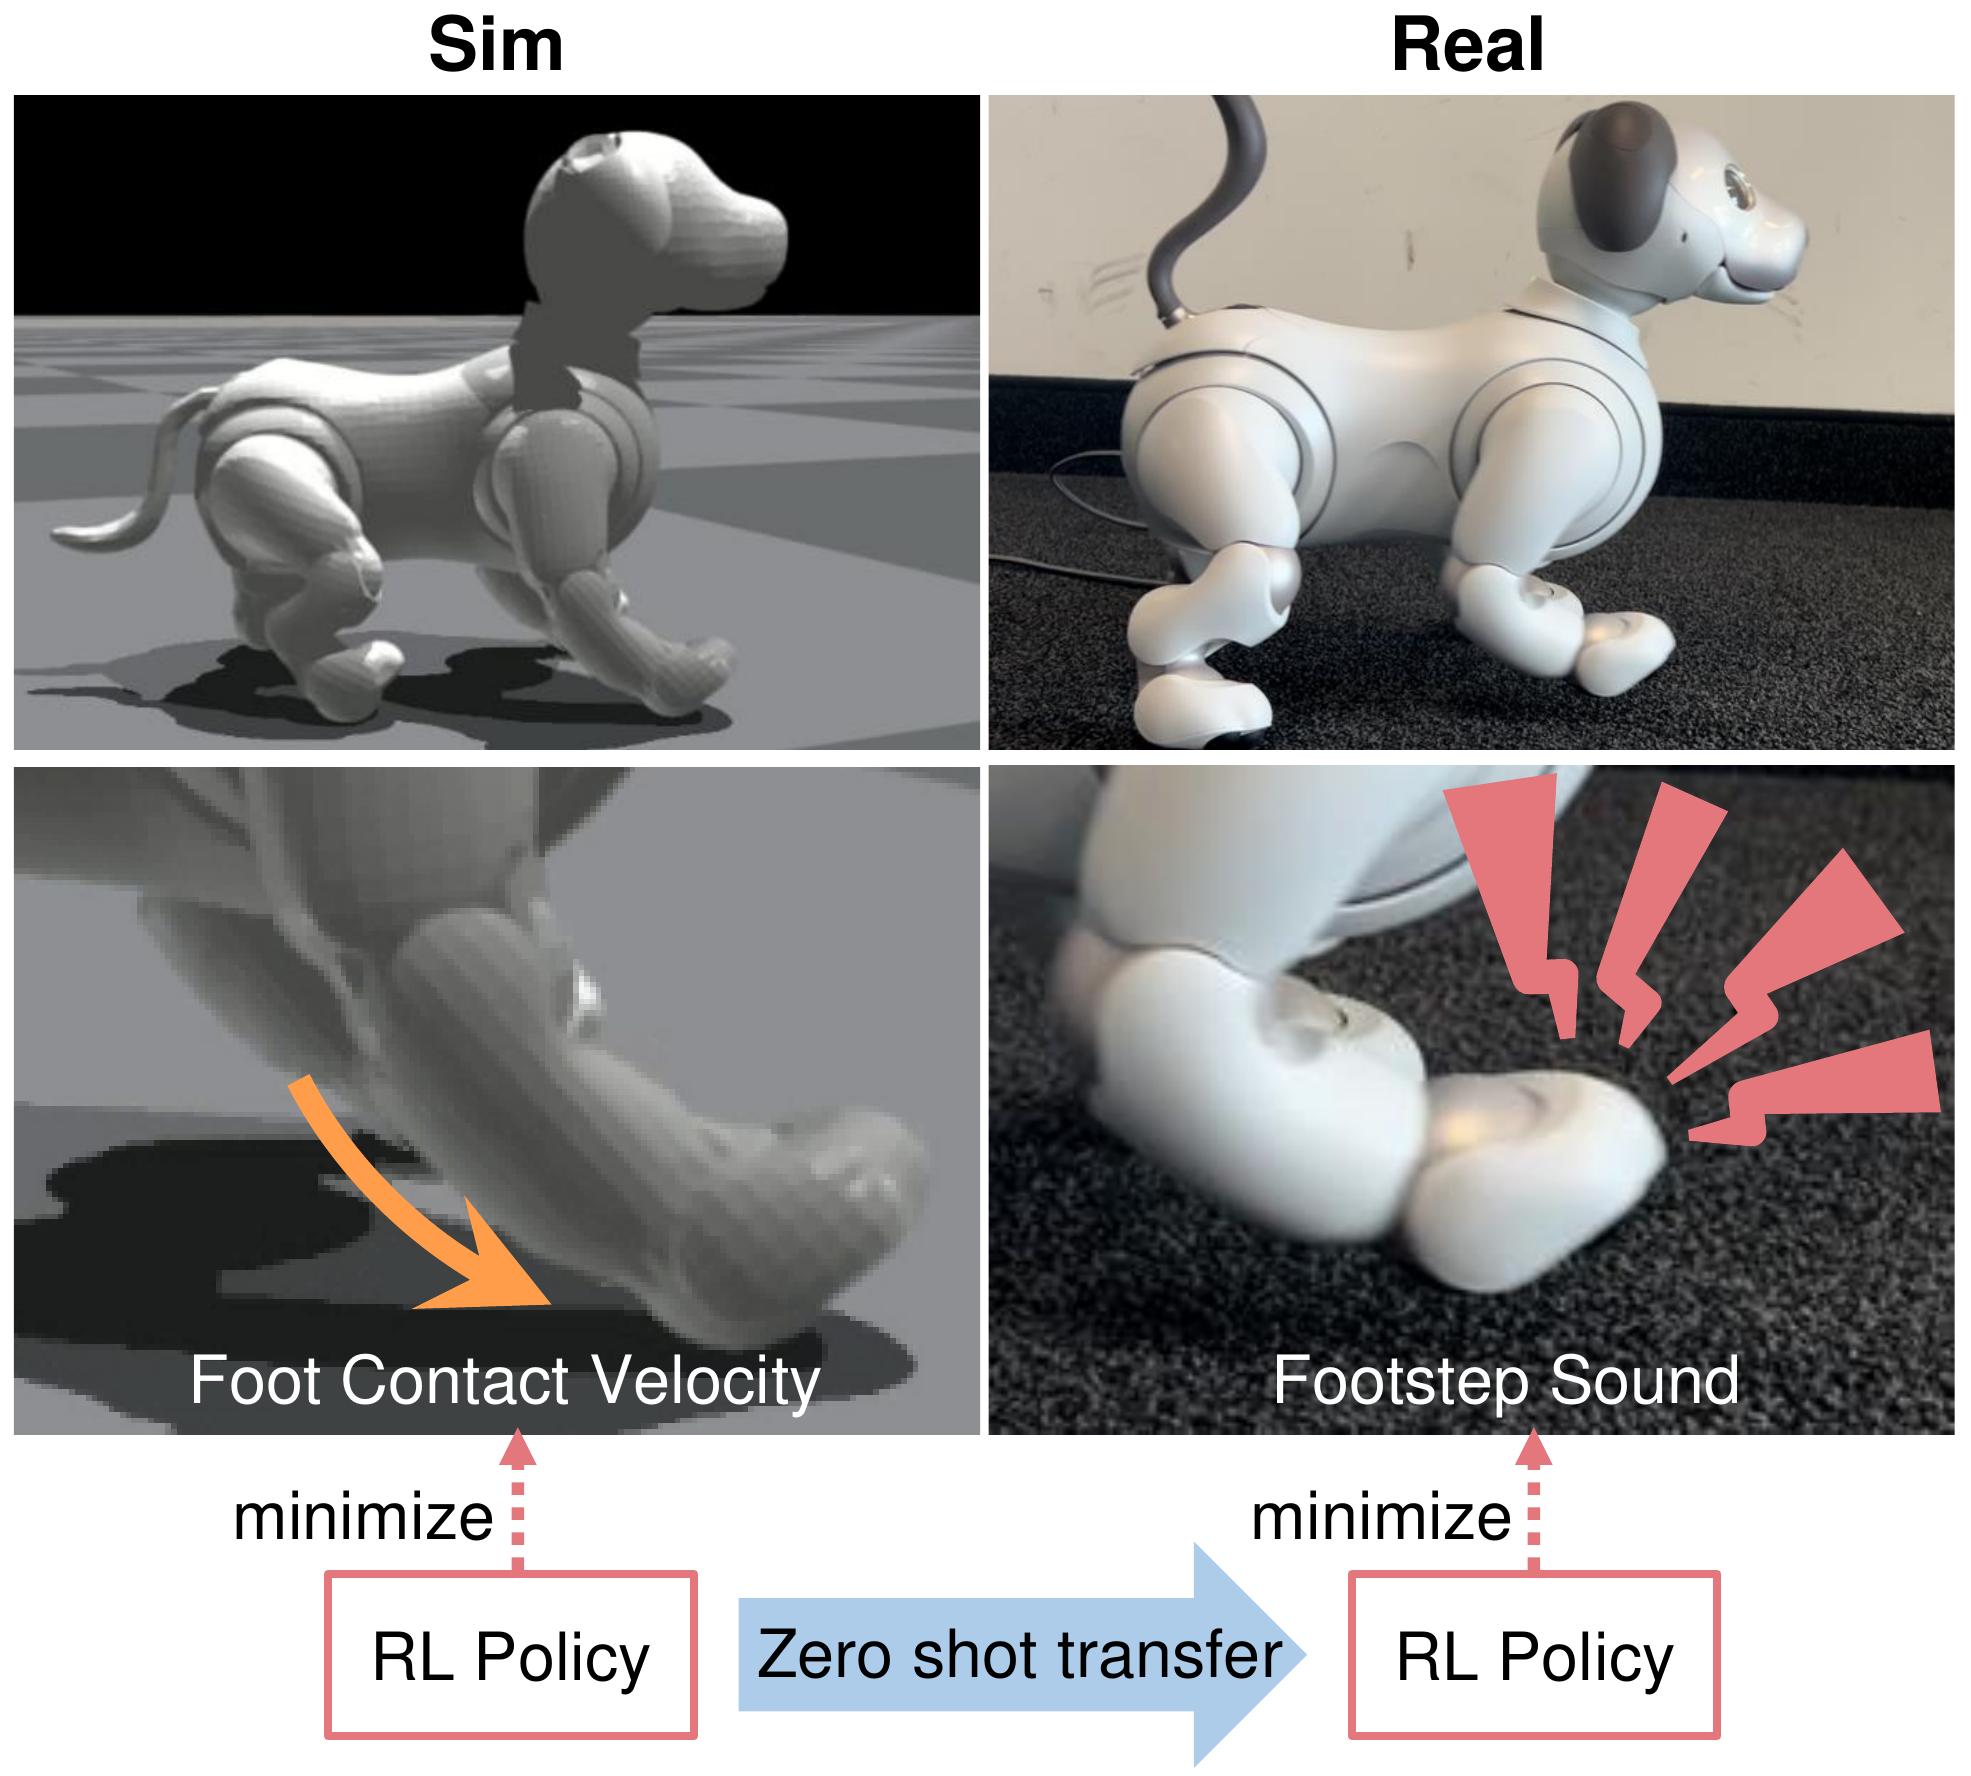
Learning Quiet Walking for a Small Home Robot
R. Watanabe, T. Miki, F. Shi, Y. Kadokawa, F. Bjelonic, K. Kawaharazuka, A. Cramariuc, M. Hutter
2025 IEEE International Conference on Robotics and Automation (ICRA2025), 2025
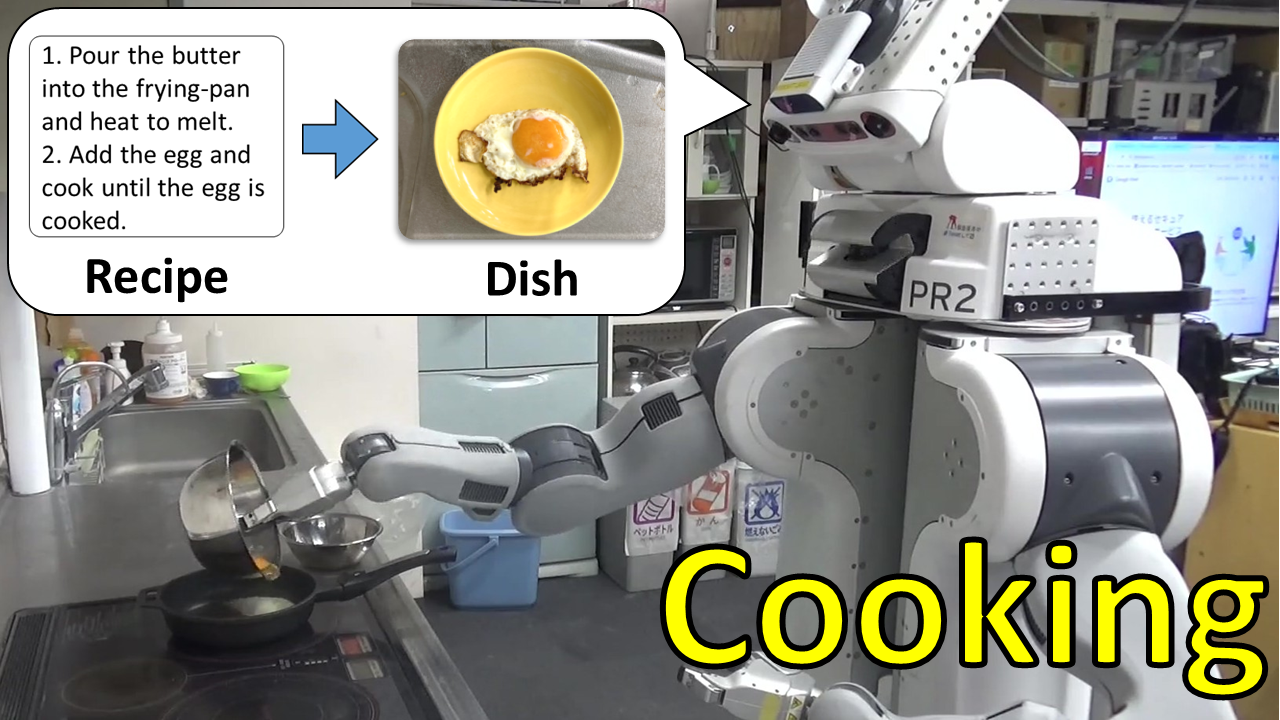
Real-world cooking robot system from recipes based on food state recognition using foundation models and PDDL
N. Kanazawa, K. Kawaharazuka, Y. Obinata, K. Okada, M. Inaba
Advanced Robotics (AR), 2024
Reflex-Based Open-Vocabulary Navigation without Prior Knowledge Using Omnidirectional Camera and Multiple Vision-Language Models
K. Kawaharazuka, Y. Obinata, N. Kanazawa, N. Tsukamoto, K. Okada, M. Inaba
Advanced Robotics (AR), 2024
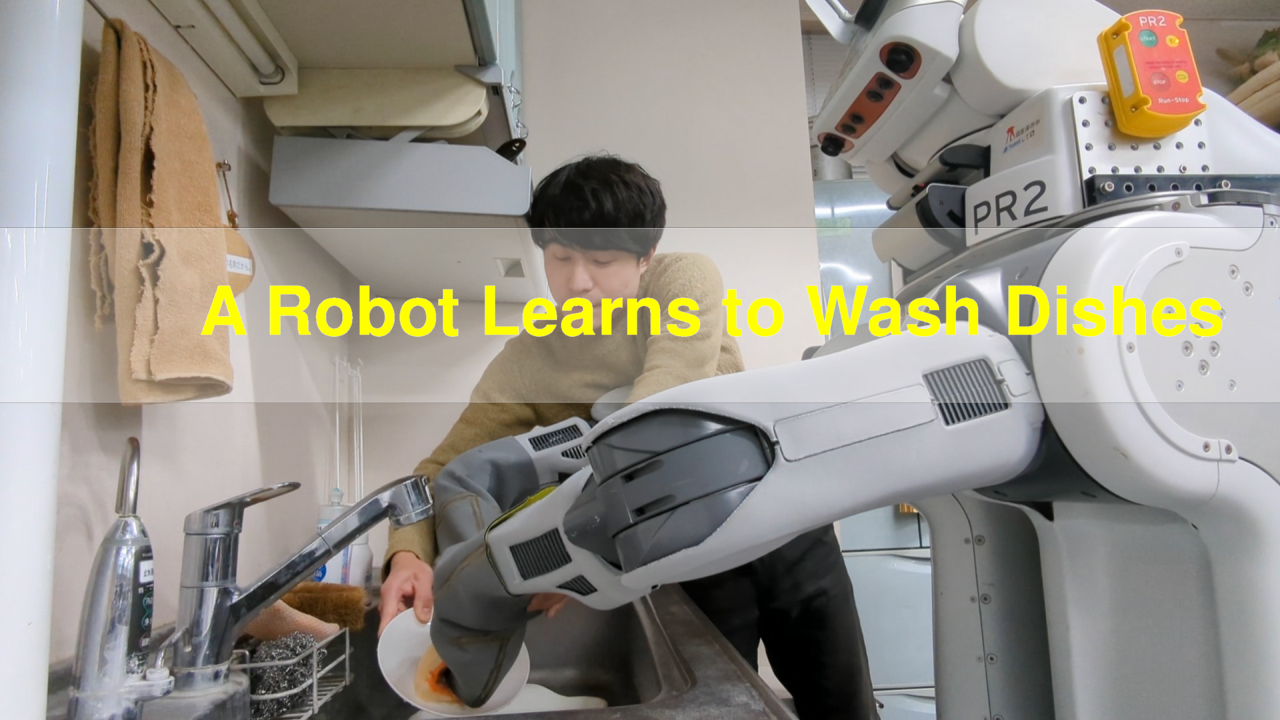
Behavioral Learning of Dish Rinsing and Scrubbing based on Interruptive Direct Teaching Considering Assistance Rate
S. Wakabayashi, K. Kawaharazuka, K. Okada, M. Inaba
Advanced Robotics (AR), 2024
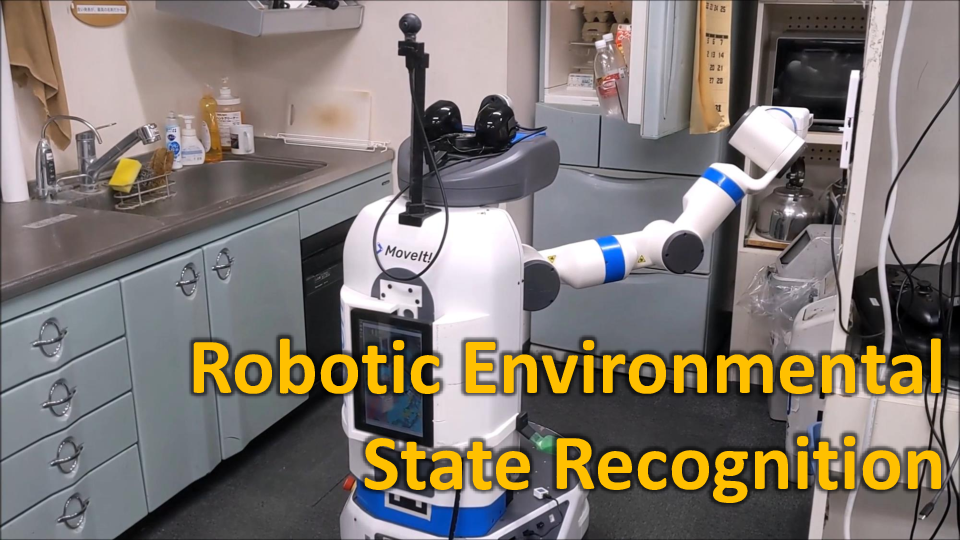
Robotic Environmental State Recognition with Pre-Trained Vision-Language Models and Black-Box Optimization
K. Kawaharazuka, Y. Obinata, N. Kanazawa, K. Okada, M. Inaba
Advanced Robotics (AR), 2024
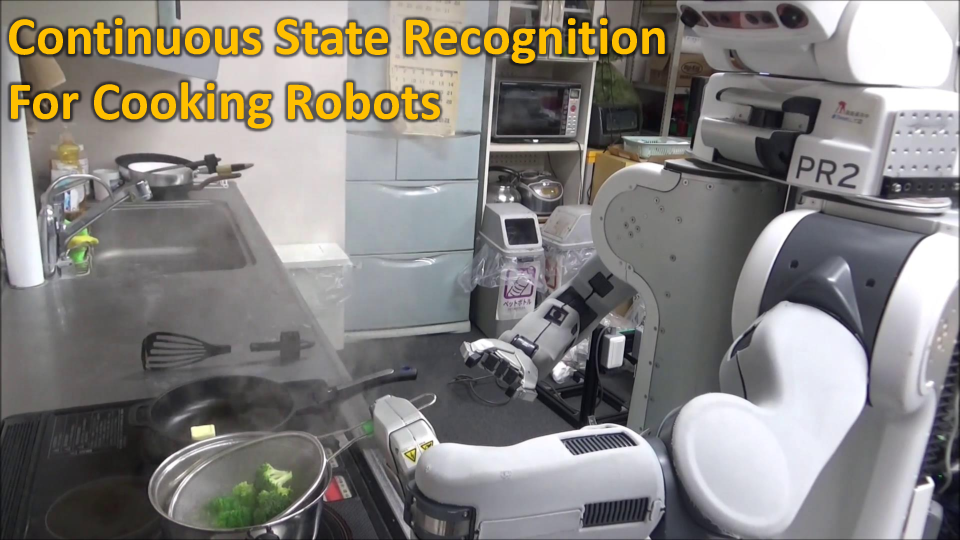
Continuous Object State Recognition for Cooking Robots Using Pre-Trained Vision-Language Models and Black-box Optimization
K. Kawaharazuka, N. Kanazawa, Y. Obinata, K. Okada, M. Inaba
IEEE Robotics and Automation Letters (RAL), 2024
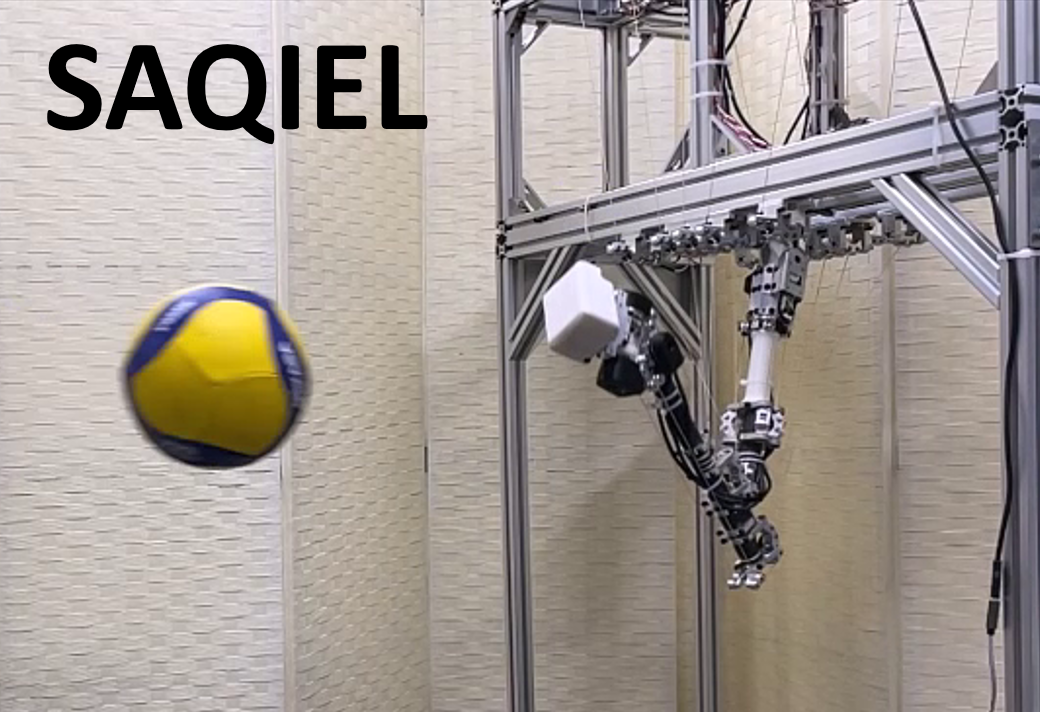
SAQIEL: Ultra-Light and Safe Manipulator with Passive 3D Wire Alignment Mechanism
T. Suzuki, M. Bando, K. Kawaharazuka, K. Okada, M. Inaba
IEEE Robotics and Automation Letters (RAL), 2024
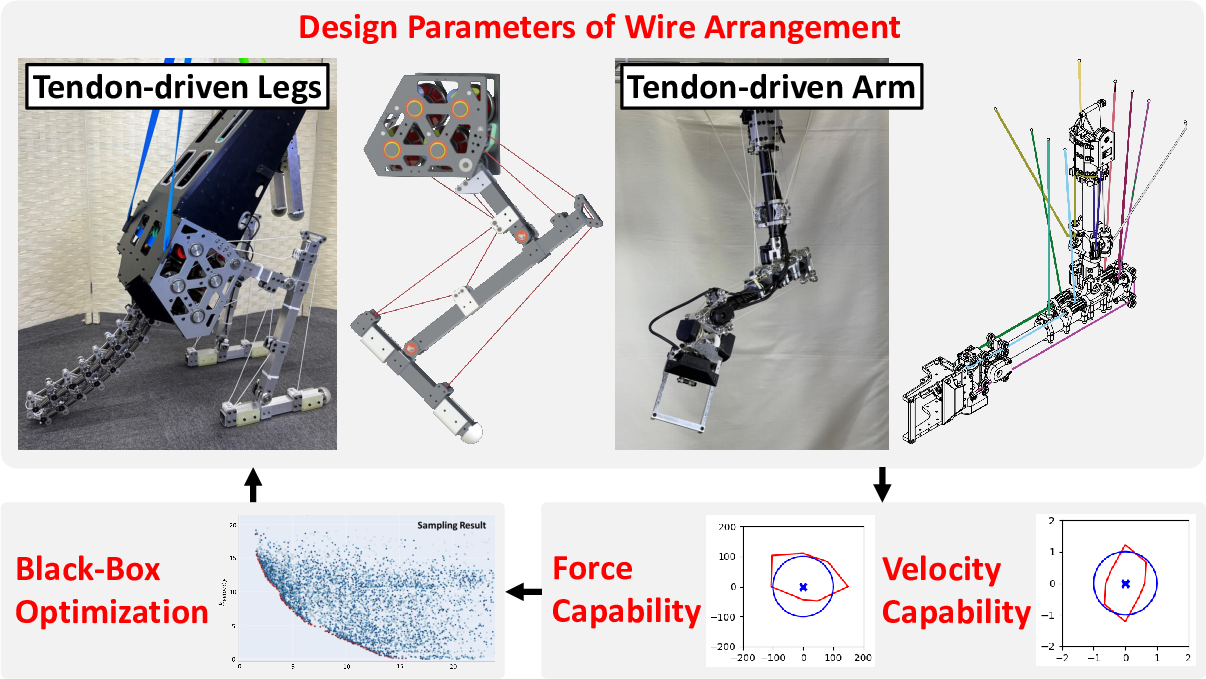
Design Optimization of Wire Arrangement With Variable Relay Points in Numerical Simulation for Tendon-Driven Robots
K. Kawaharazuka, S. Yoshimura, T. Suzuki, K. Okada, M. Inaba
IEEE Robotics and Automation Letters (RAL), 2024
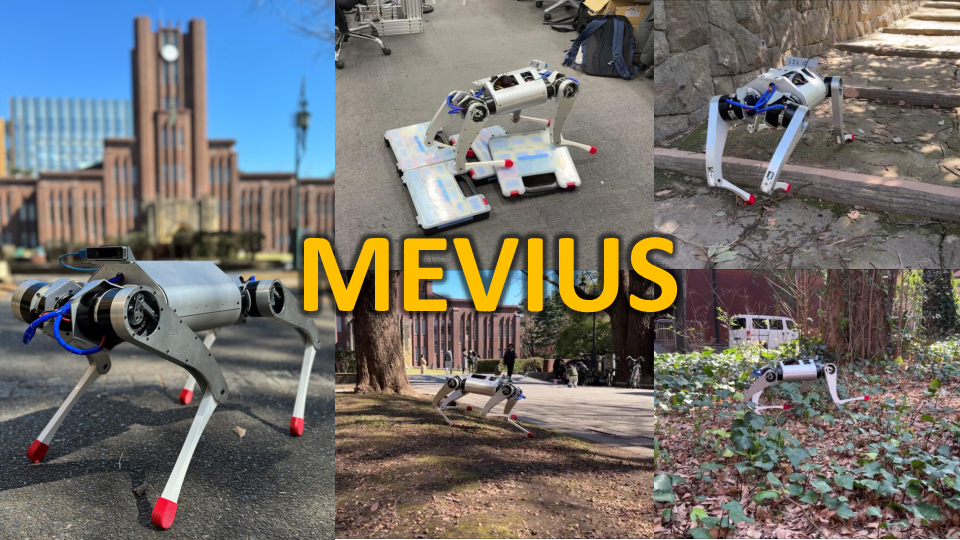
MEVIUS: A Quadruped Robot Easily Constructed through E-Commerce with Sheet Metal Welding and Machining
K. Kawaharazuka, S. Inoue, T. Suzuki, S. Yuzaki, S. Sawaguchi, K. Okada, M. Inaba
2024 IEEE-RAS International Conference on Humanoid Robots (HUMANOIDS2024), 2024
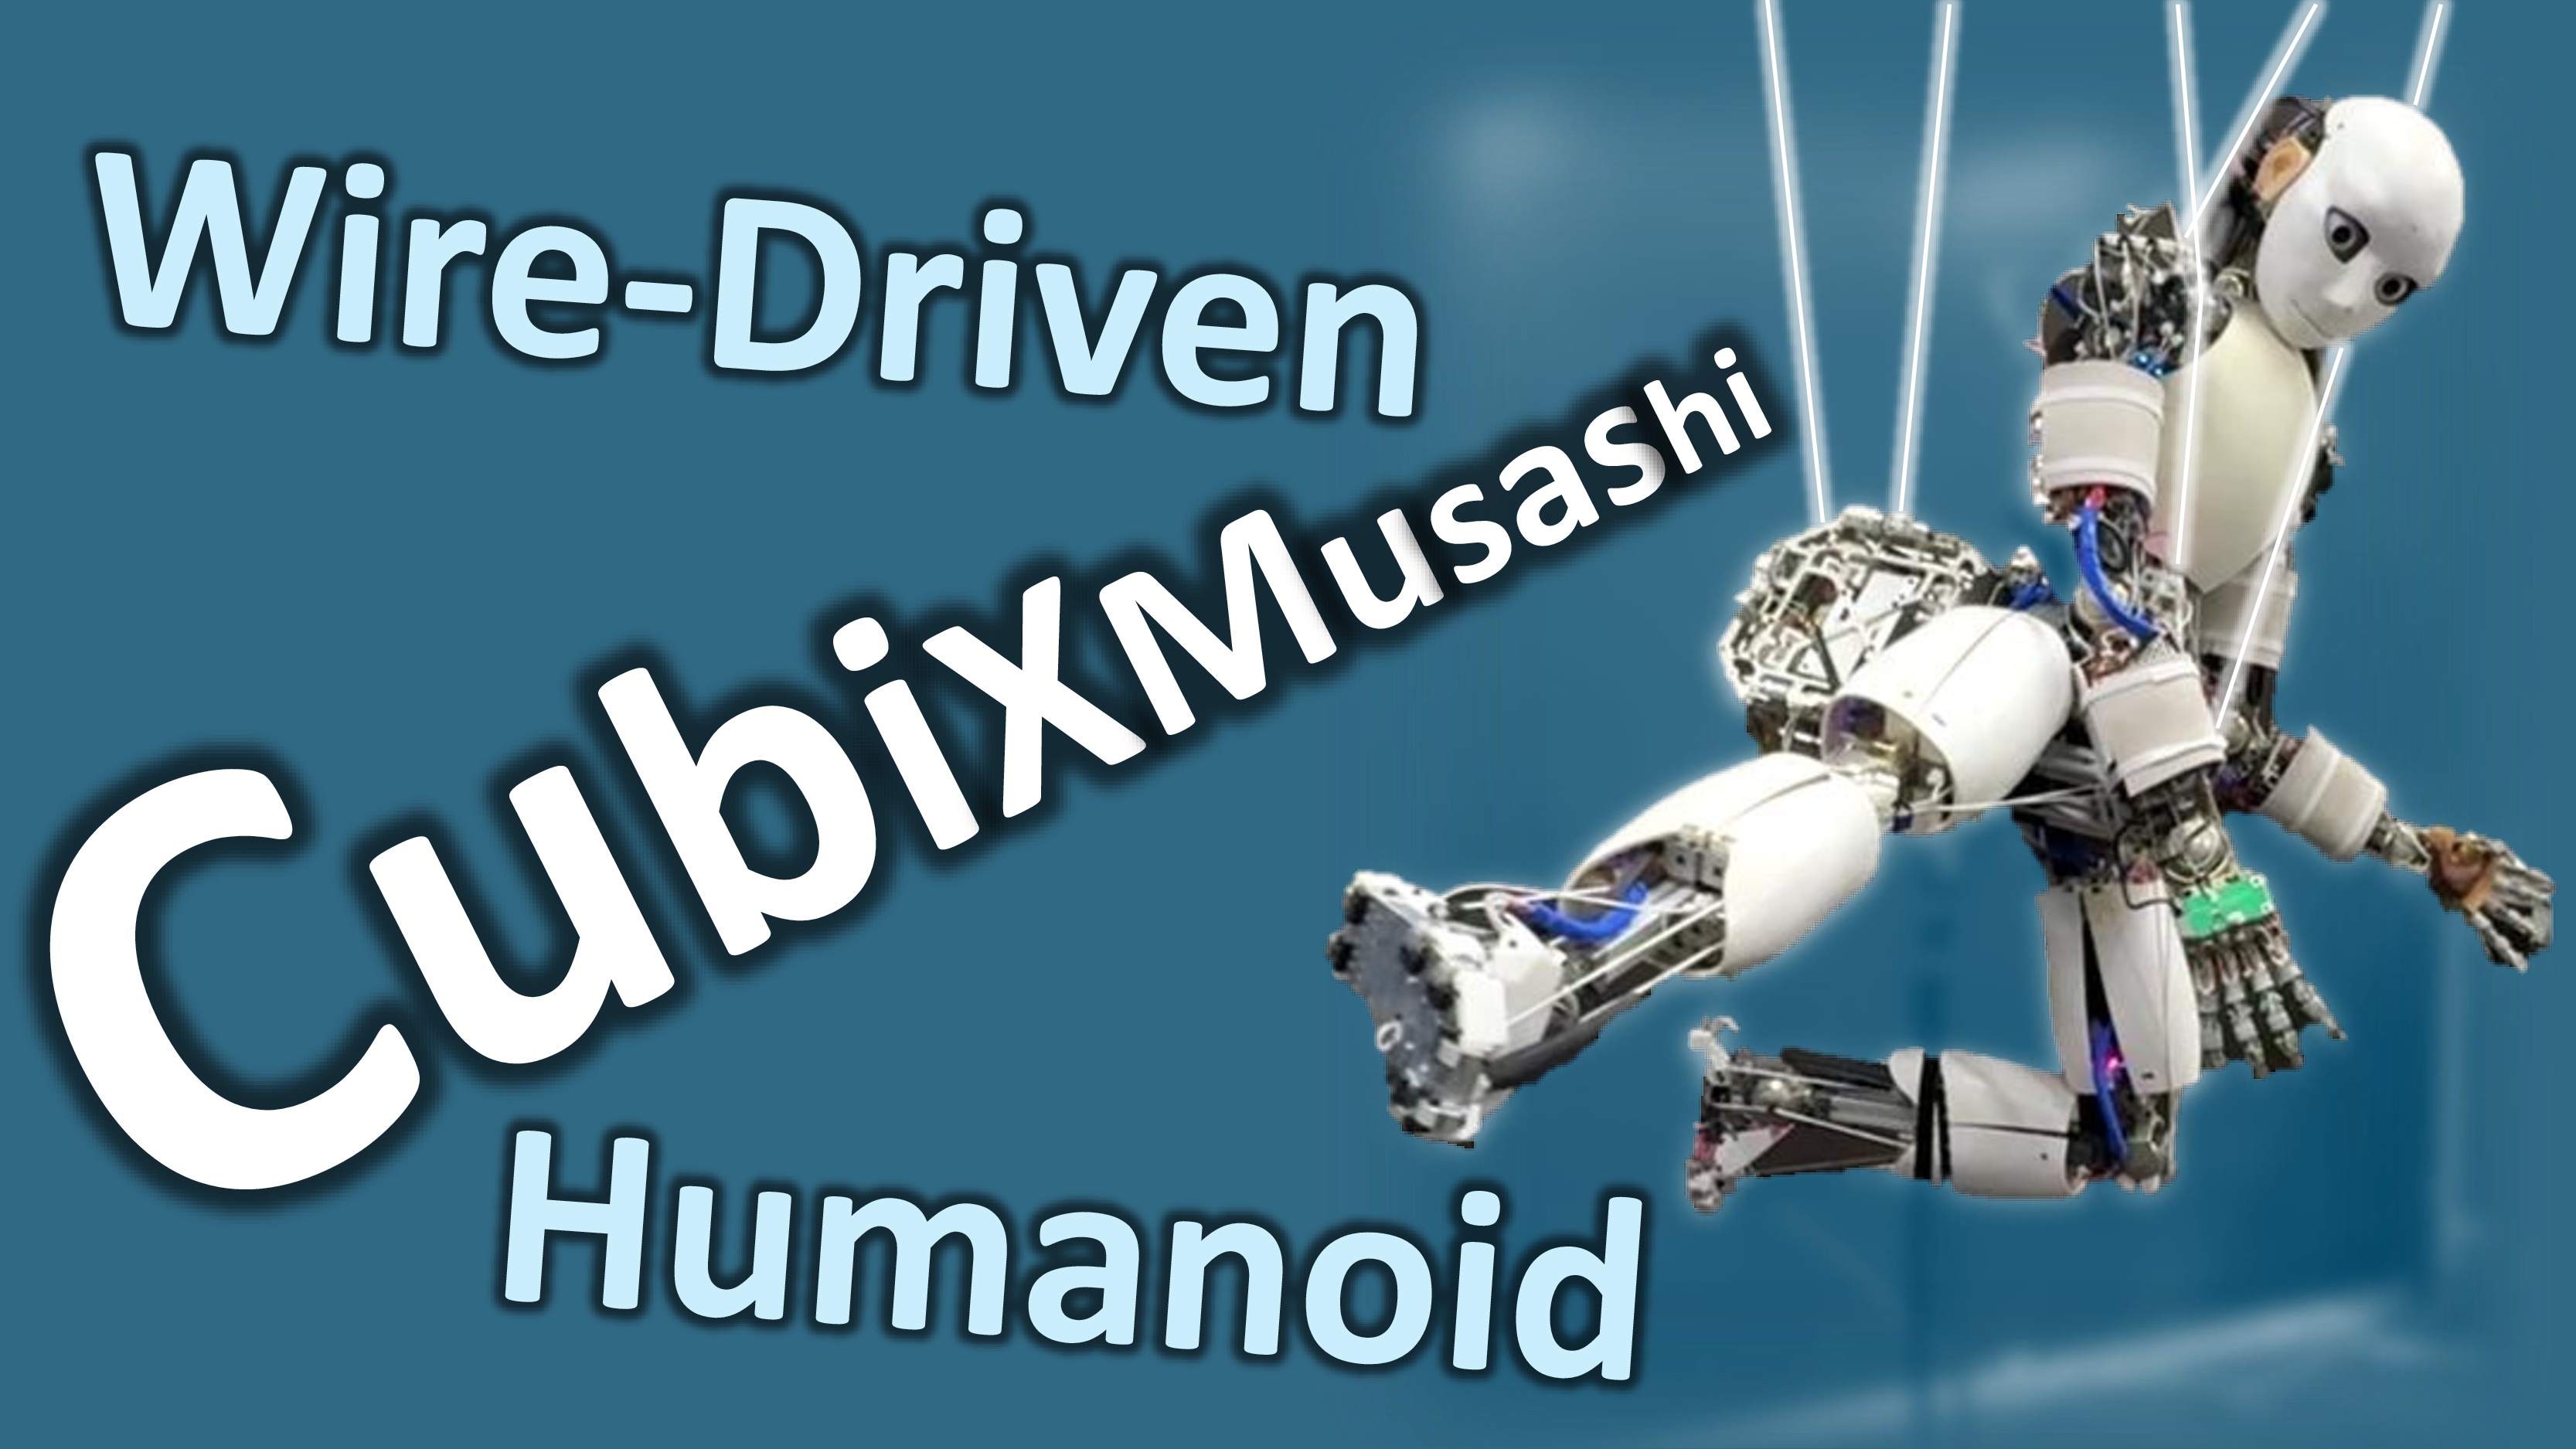
CubiXMusashi: Fusion of Wire-Driven CubiX and Musculoskeletal Humanoid Musashi toward Unlimited Performance
S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, Y. Ribayashi, Y. Sahara, K. Okada
2024 IEEE-RAS International Conference on Humanoid Robots (HUMANOIDS2024), 2024
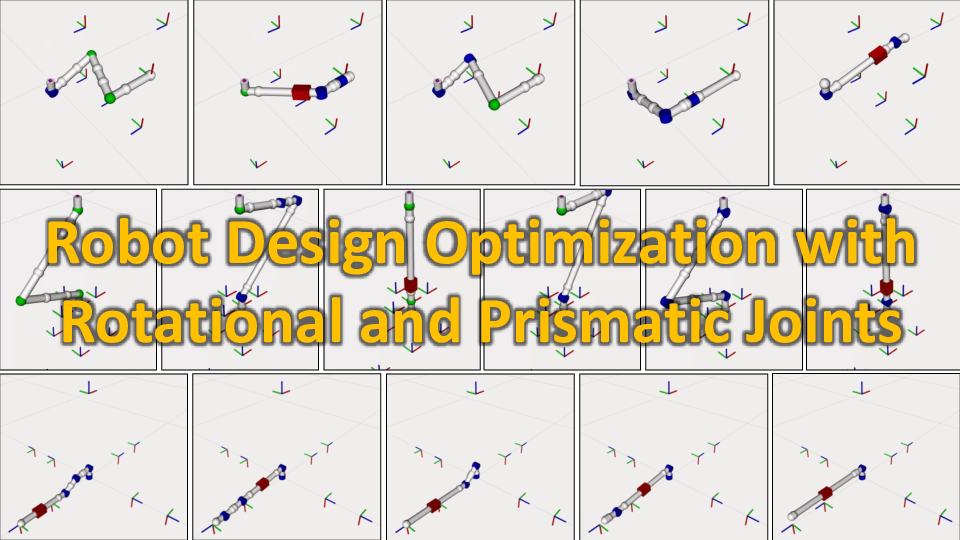
Robot Design Optimization with Rotational and Prismatic Joints Using Black-Box Multi-Objective Optimization
K. Kawaharazuka, K. Okada, M. Inaba
2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2024), 2024
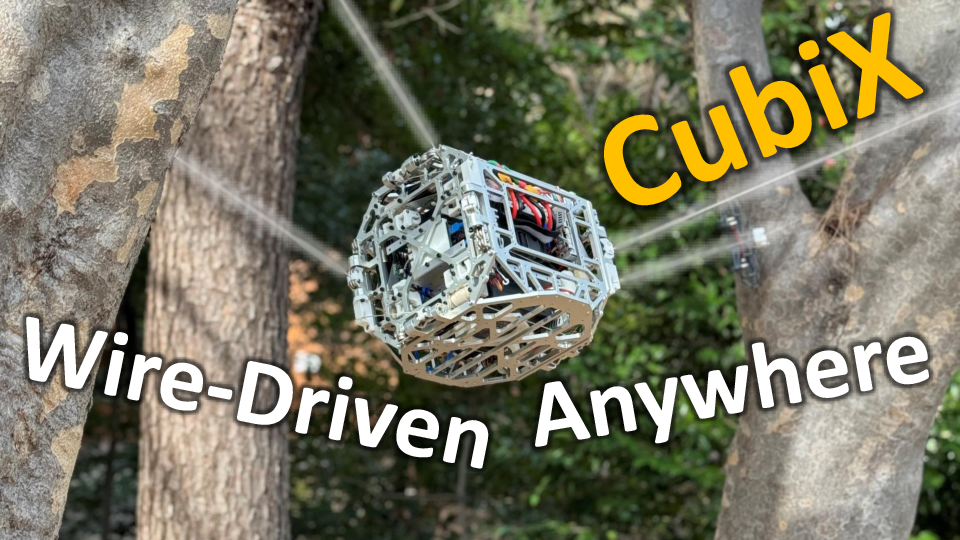
CubiX: Portable Wire-Driven Parallel Robot Connecting to and Utilizing the Environment
S. Inoue, K. Kawaharazuka, T. Suzuki, S. Yuzaki, K. Okada, M. Inaba
2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2024), 2024
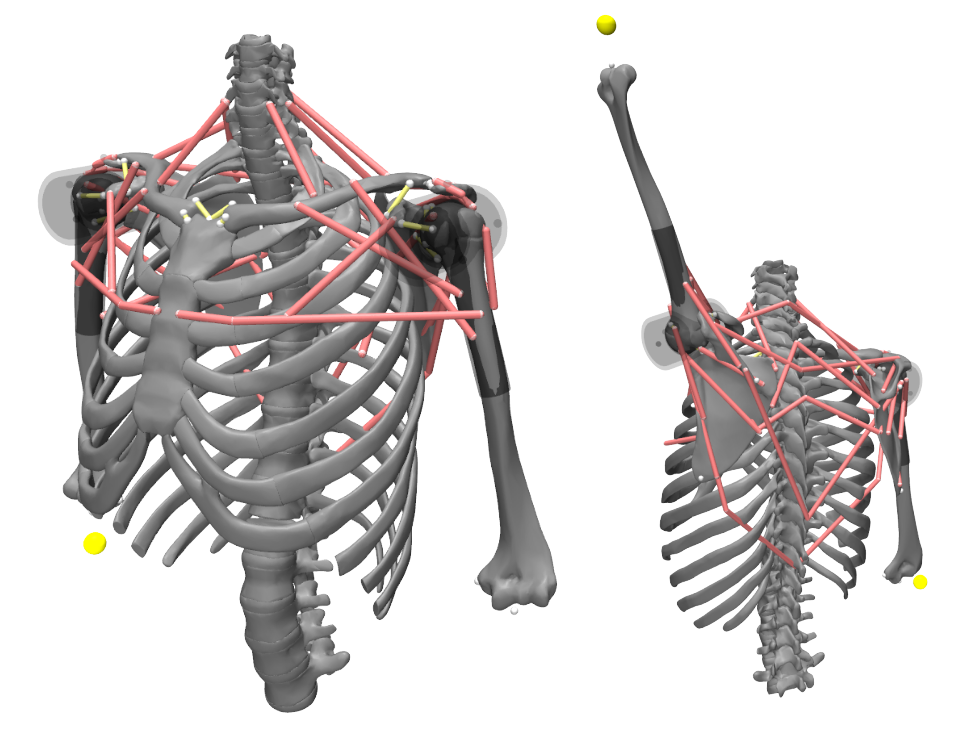
Construction of Musculoskeletal Simulation for Shoulder Complex with Ligaments and Its Validation via Model Predictive Control
Y. Sahara, A. Miki, Y. Ribayashi, S. Yoshimura, K. Kawaharazuka, K. Okada, M. Inaba
2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2024), 2024
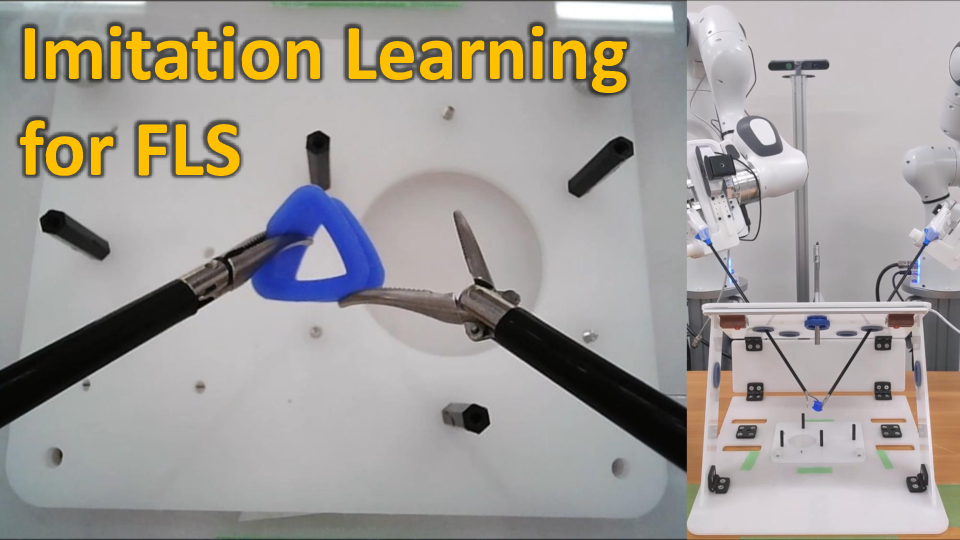
Robotic Constrained Imitation Learning for the Peg Transfer Task in Fundamentals of Laparoscopic Surgery
K. Kawaharazuka, K. Okada, M. Inaba
2024 IEEE International Conference on Robotics and Automation (ICRA2024), 2024
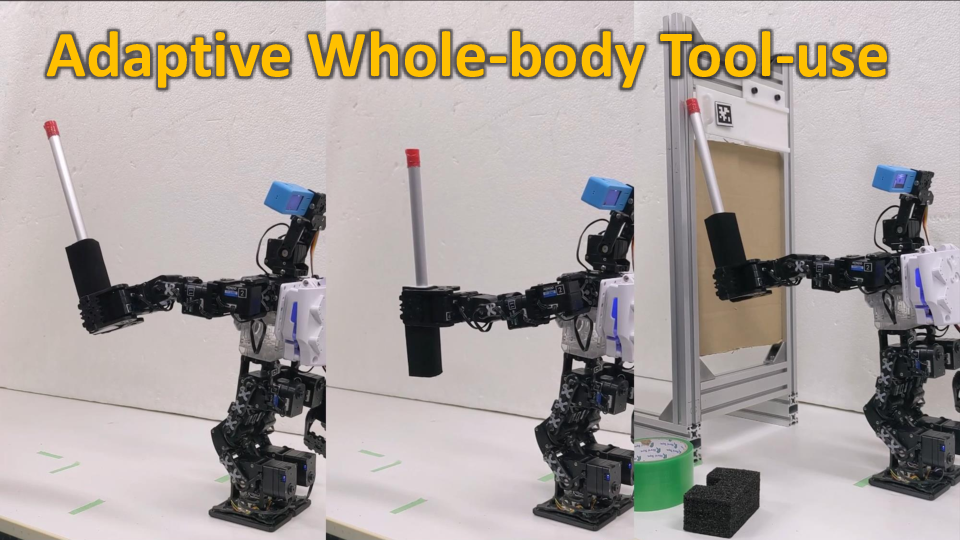
Adaptive Whole-body Robotic Tool-use Learning on Low-rigidity Plastic-made Humanoids Using Vision and Tactile Sensors
K. Kawaharazuka, K. Okada, M. Inaba
2024 IEEE International Conference on Robotics and Automation (ICRA2024), 2024
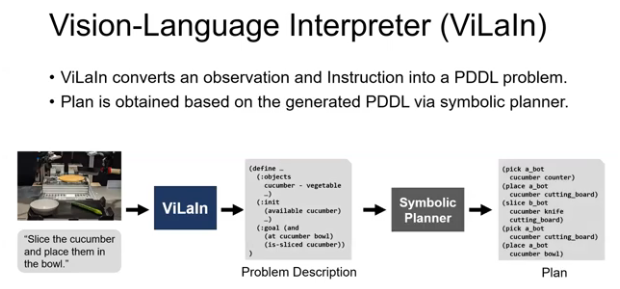
Vision-Language Interpreter for Robot Task Planning
K. Shirai, C. C. Beltran-Hernandez, M. Hamaya, A. Hashimoto, S. Tanaka, K. Kawaharazuka, K. Tanaka, Y. Ushiku, S. Mori
2024 IEEE International Conference on Robotics and Automation (ICRA2024), 2024
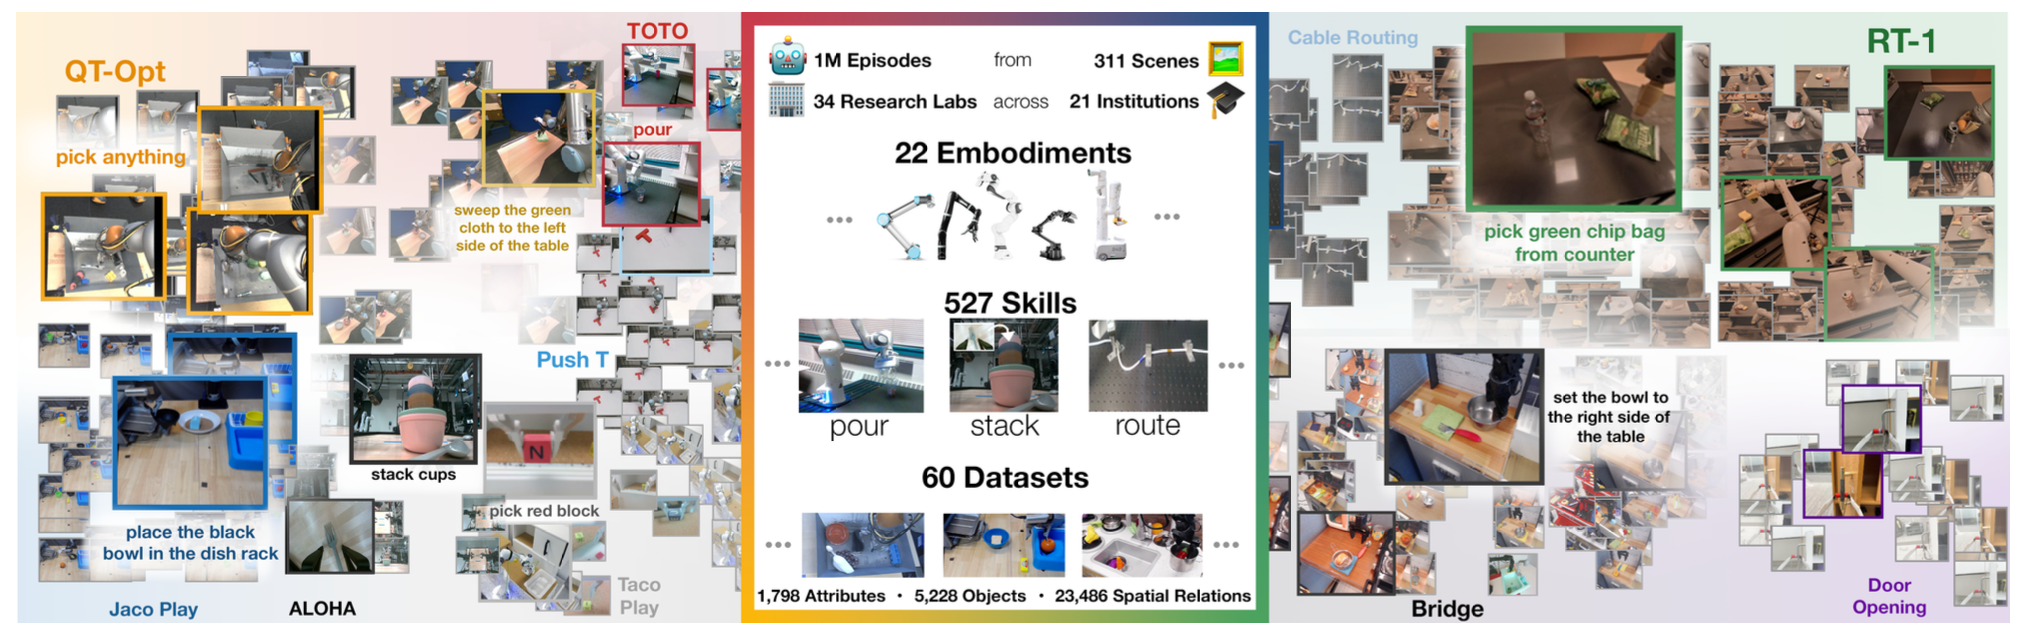
Open X-Embodiment: Robotic Learning Datasets and RT-X Models
Open X-Embodiment Collaboration
2024 IEEE International Conference on Robotics and Automation (ICRA2024), 2024
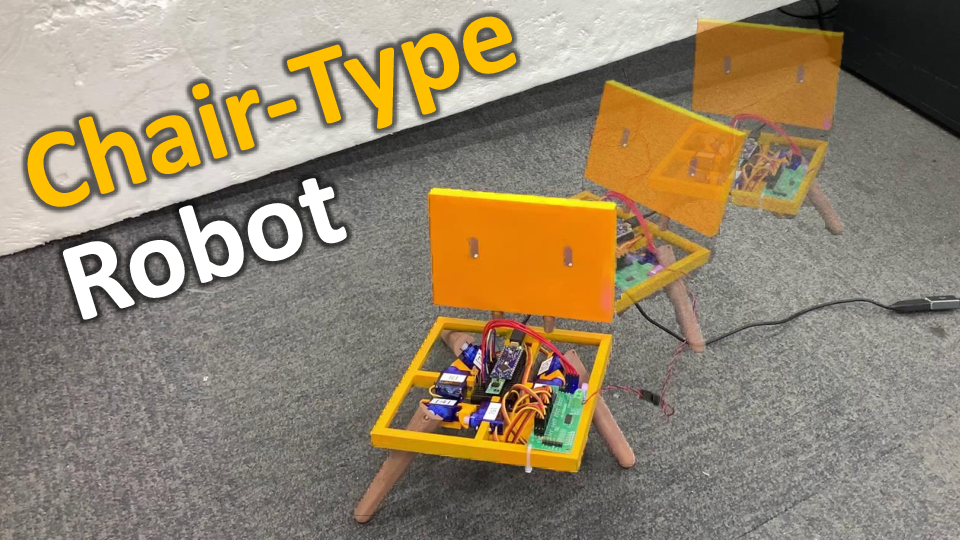
Body Design and Gait Generation of Chair-Type Asymmetrical Tripedal Low-rigidity Robot
S. Inoue, K. Kawaharazuka, K. Okada, M. Inaba
2024 IEEE International Conference on Soft Robotics (ROBOSOFT2024), 2024
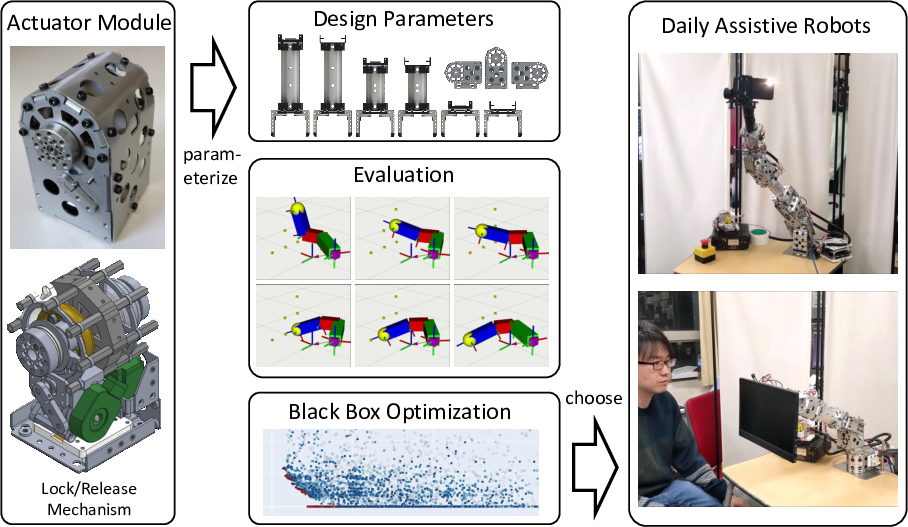
Daily Assistive Modular Robot Design Based on Multi-Objective Black-Box Optimization
K. Kawaharazuka, T. Makabe, K. Okada, M. Inaba
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2023), 2023
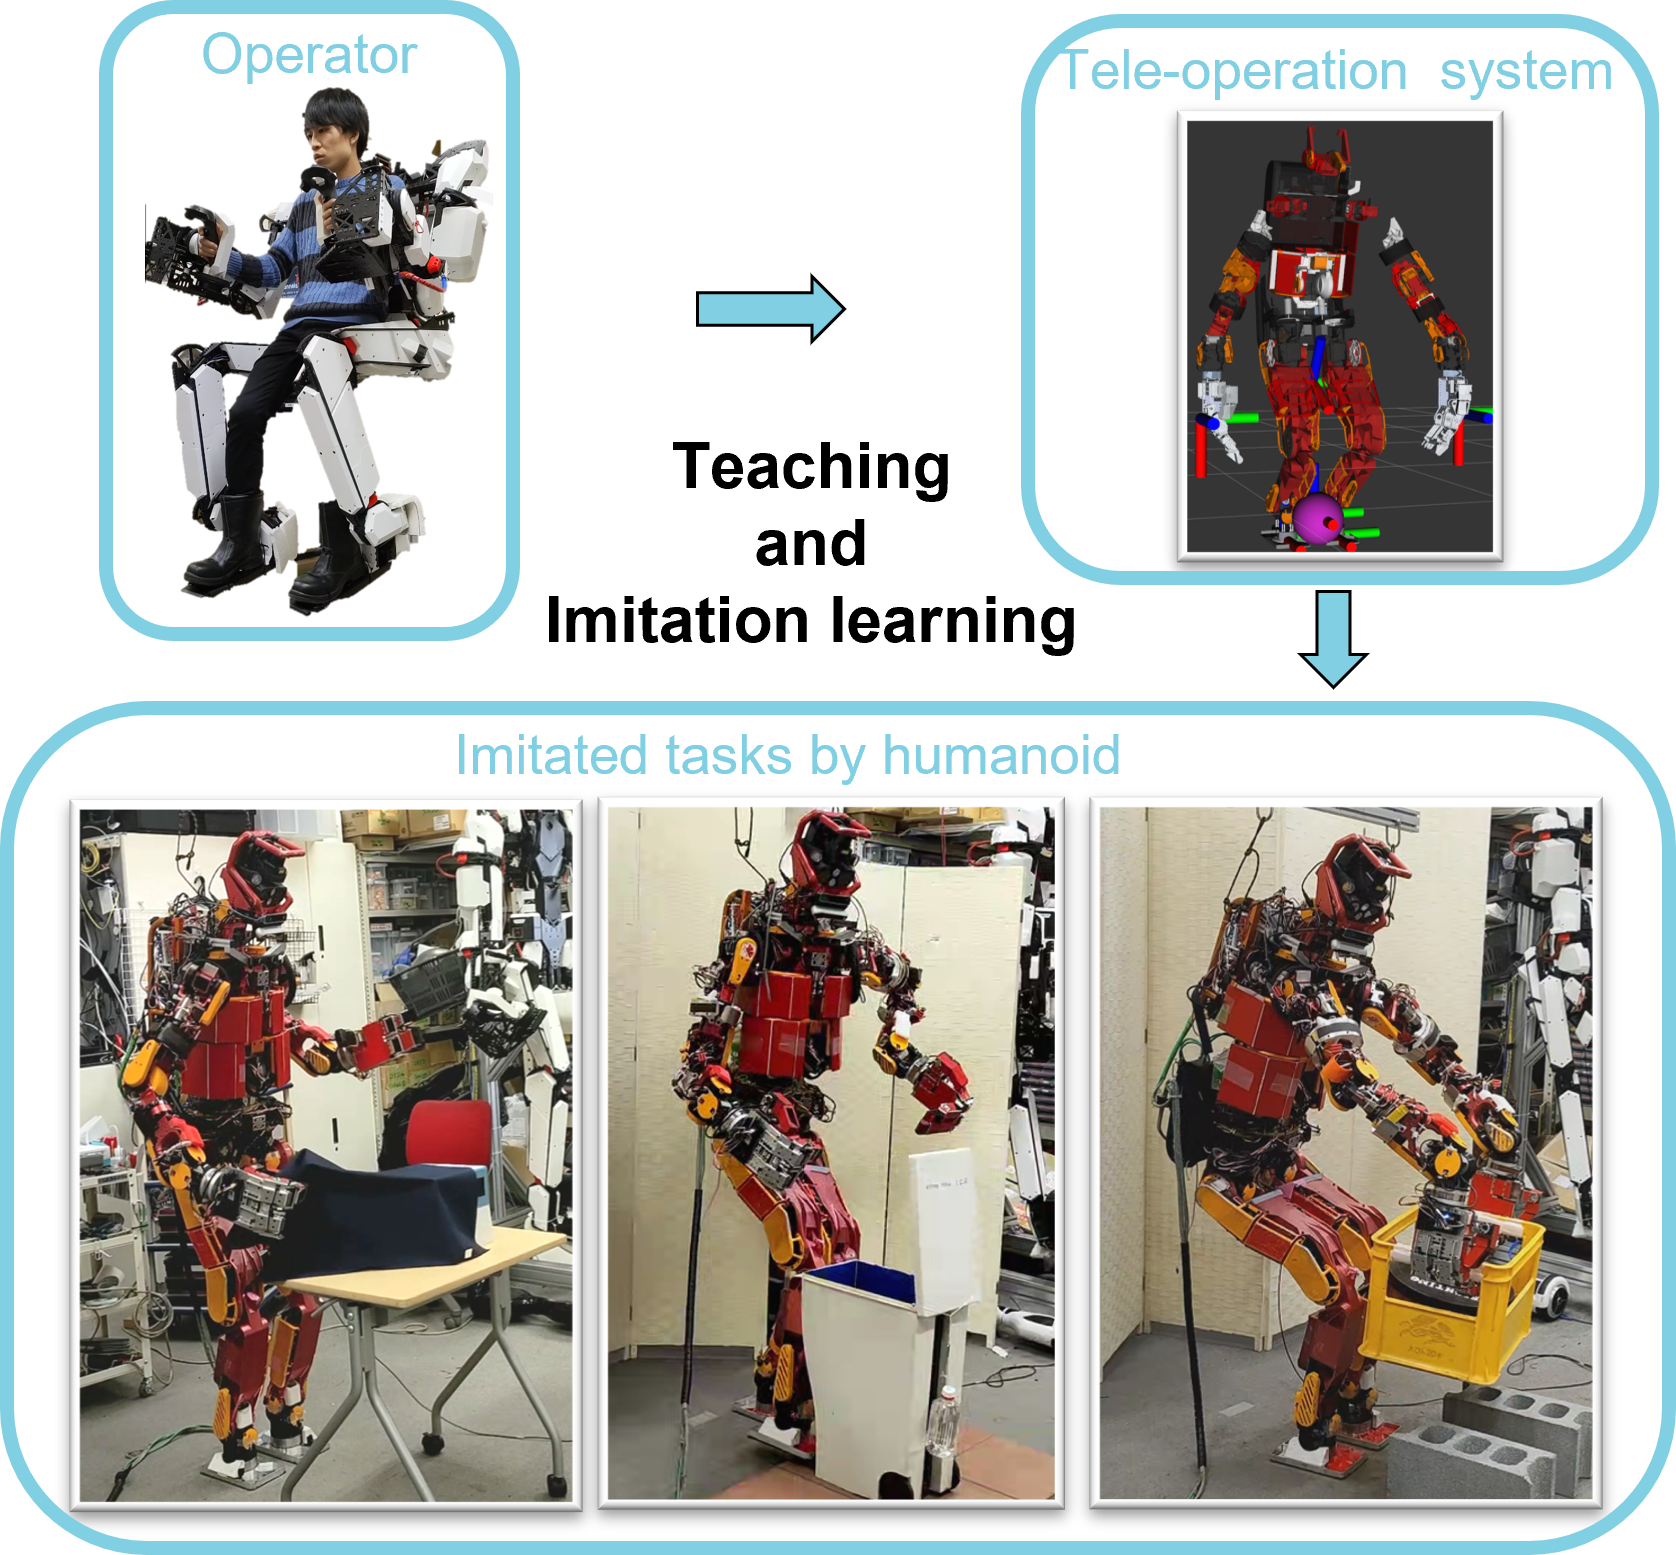
Development of a Whole-Body Work Imitation Learning System by a Biped and Bi-Armed Humanoid
Y. Matsuura, K. Kawaharazuka, N. Hiraoka, K. Kojima, K. Okada, M. Inaba
2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2023), 2023
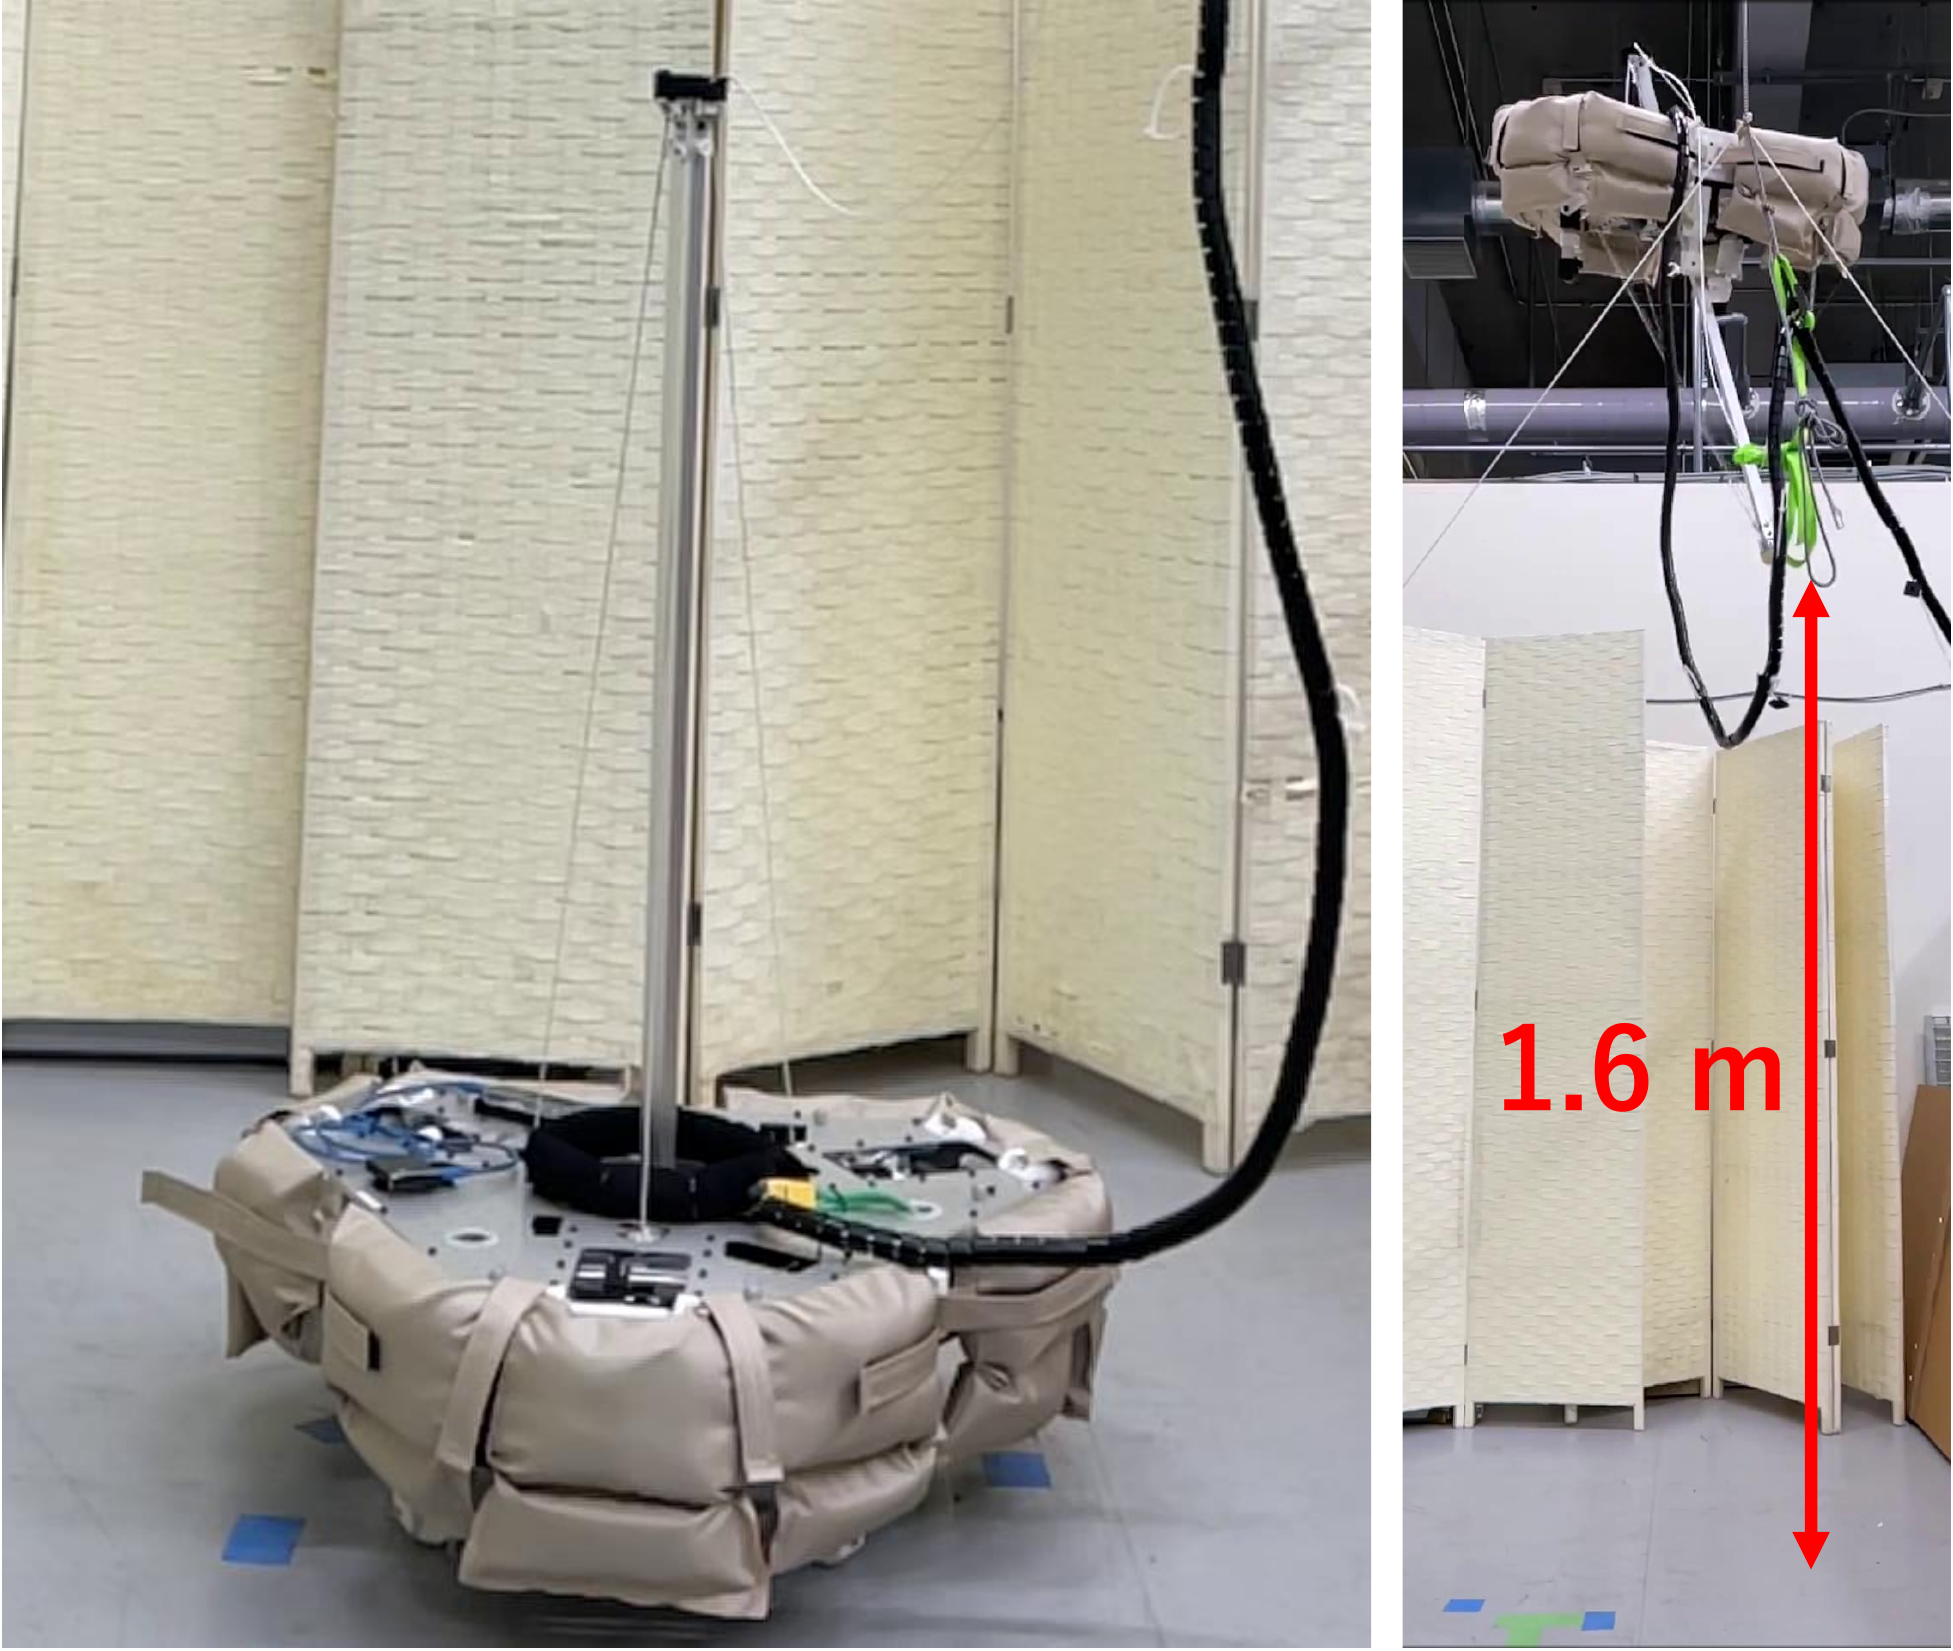
RAMIEL: A Parallel-Wire Driven Monopedal Robot for High and Continuous Jumping
T. Suzuki, Y. Toshimitsu, Y. Nagamatsu, K. Kawaharazuka, A. Miki, Y. Ribayashi, M. Bando, K. Kojima, Y. Kakiuchi, K. Okada, M. Inaba
2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS2022), 2022